Industries
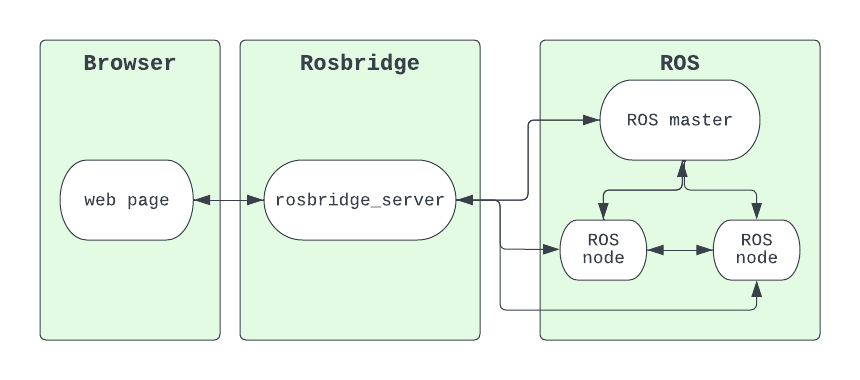
Talk to your ROS 1 robot from the web using WebSockets
Downloading Debian packages to set up the latest LTS release for ROS 2 on your Linux machine
Automate building re-usable base images for your hobby robots
How to convert your ROS 2 files into MCAP files
Downloading Debian packages to set up ROS on your Linux machine
Downloading Debian packages to set up ROS 2 on your Linux machine
Using the MCAP C++ writer to record robotics data
Use Foxglove with the robot kit to start understanding your first robot
A new and simplified way to record your robotics data
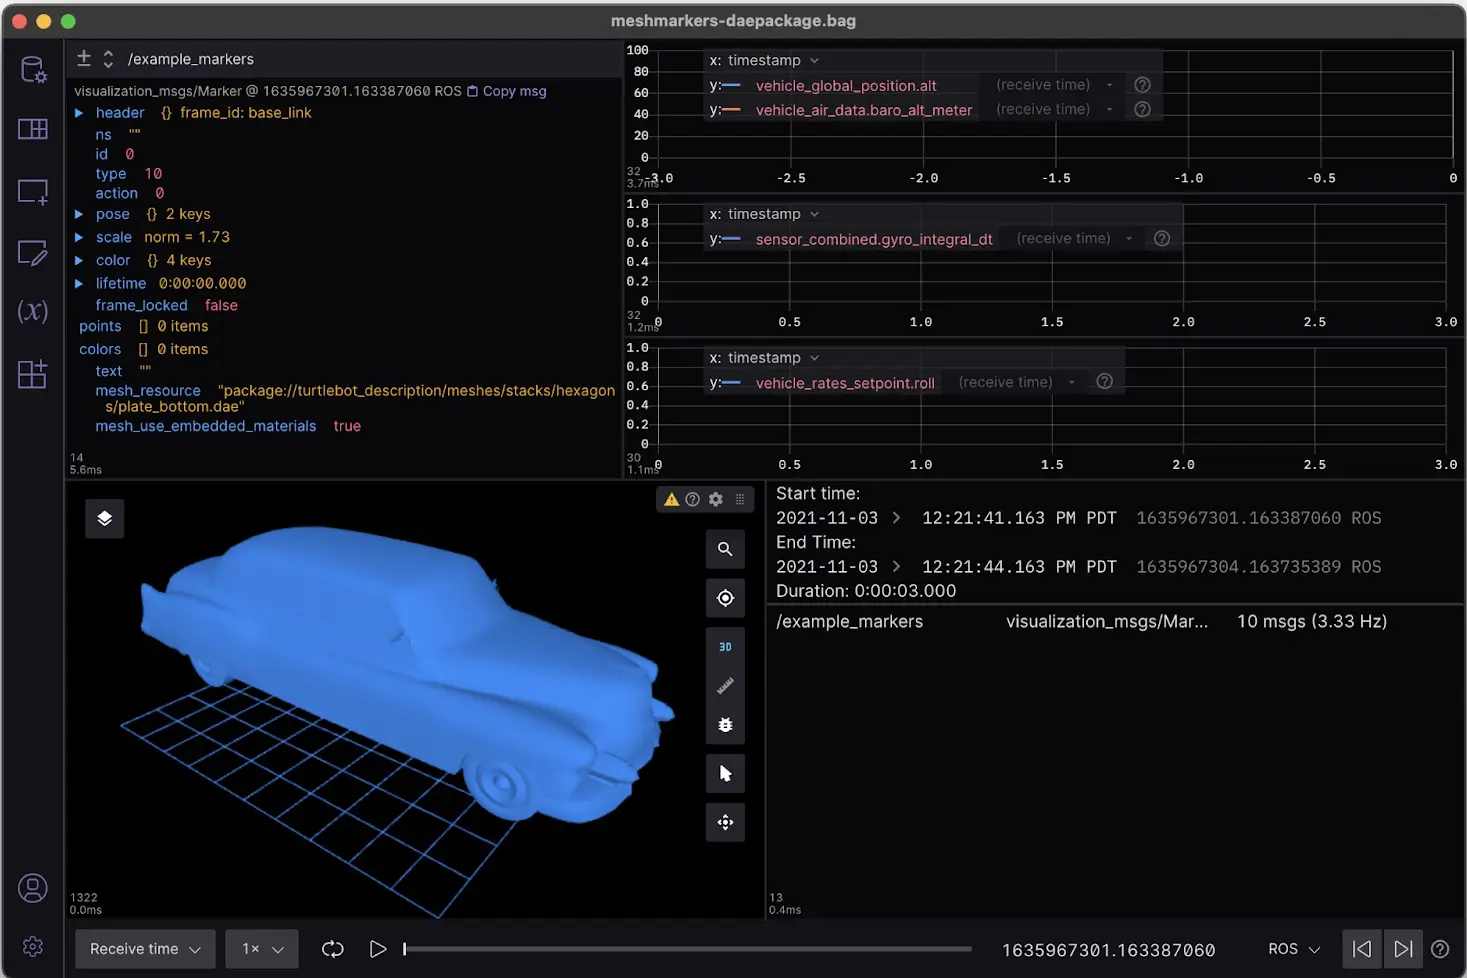
Loading mesh resources inside Foxglove's 3D panel
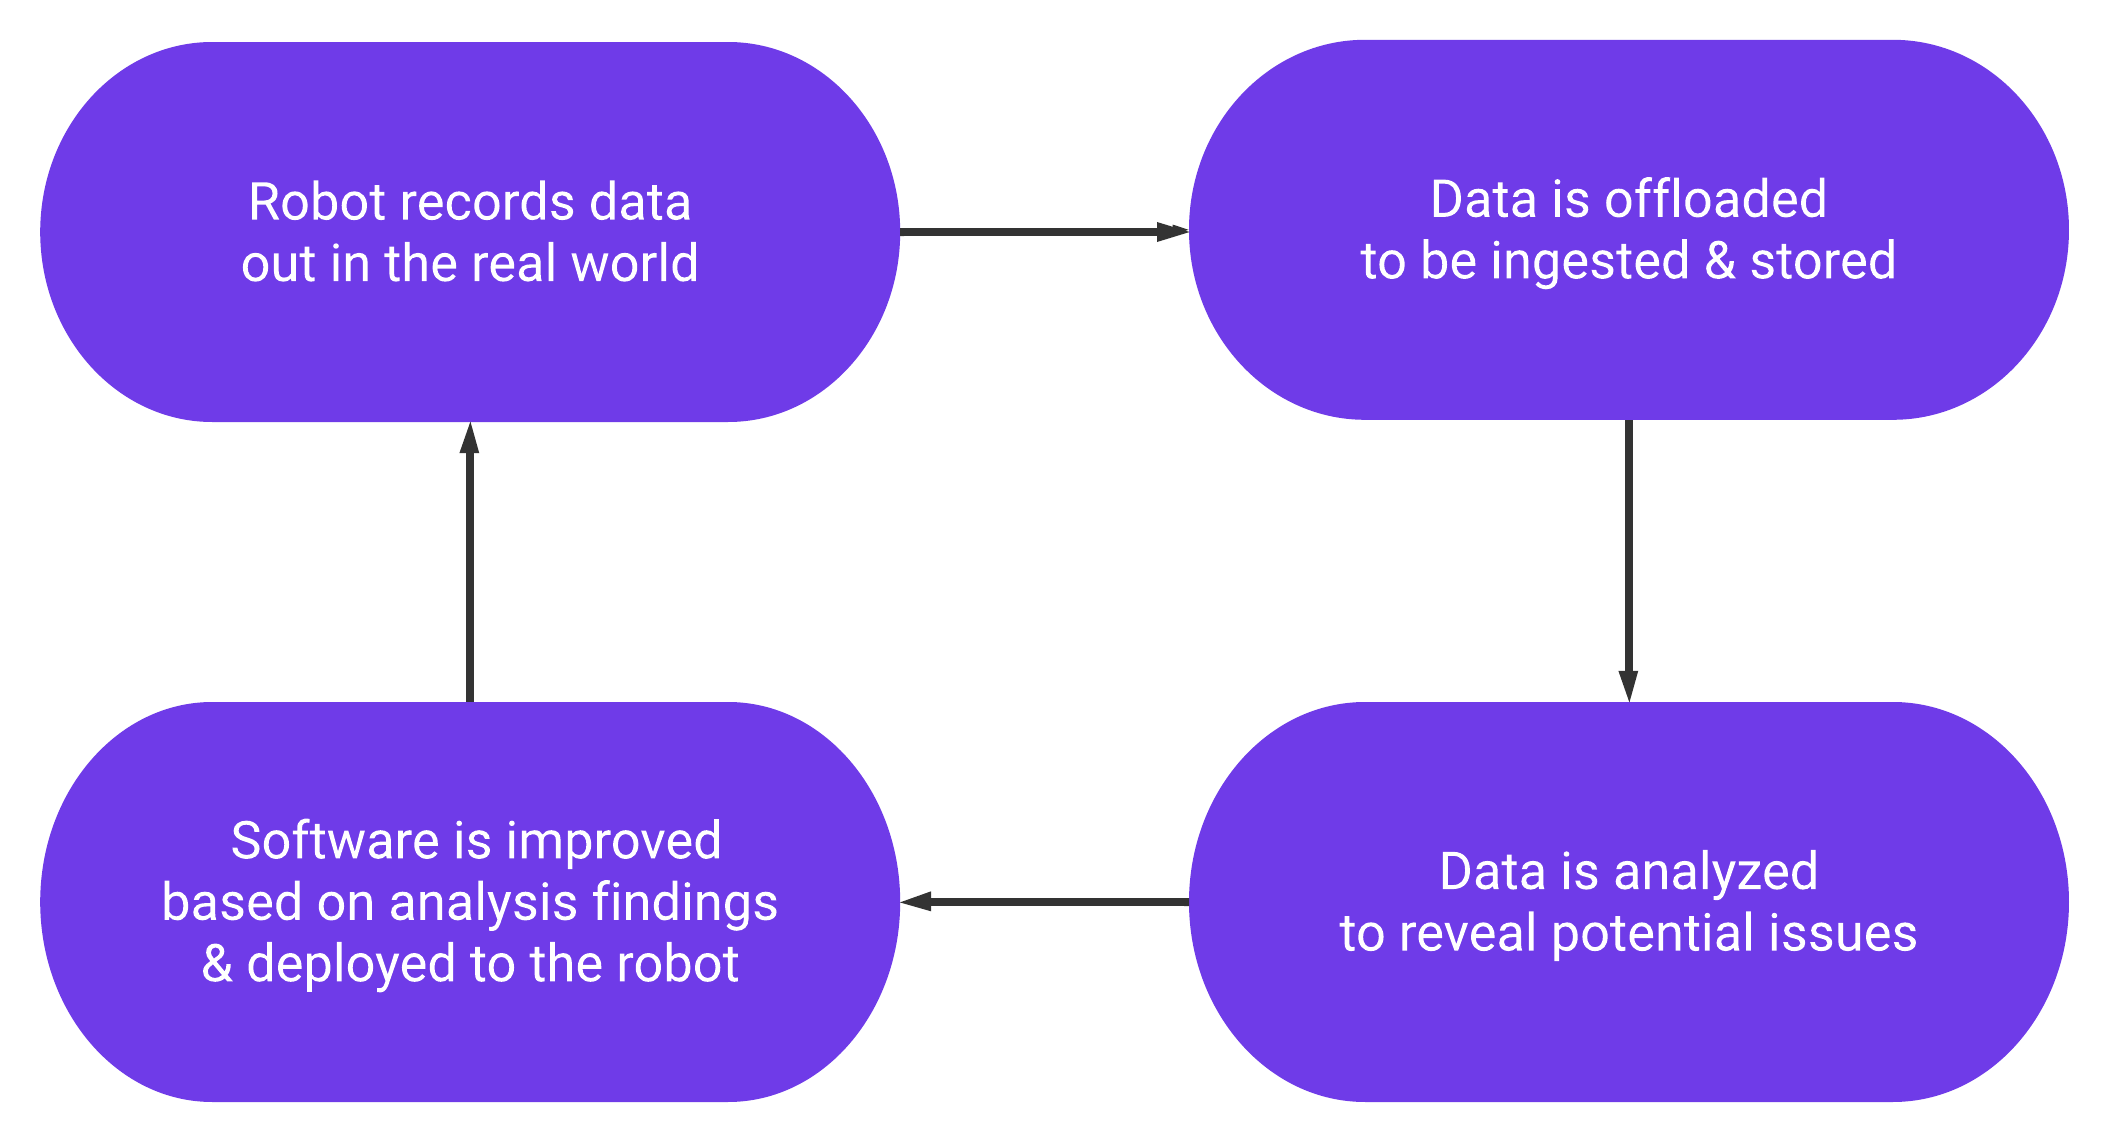
Trade-offs to consider when collecting data for analysis
Use turtlesim and Foxglove to learn how to explore robotics data
How the Robot Operating System (ROS) powers tomorrow’s robots.
Get started in robotics with the Duckiebot and Foxglove
No posts found.