Blog

Hero image for Using ROS Diagnostics in Robotics Operations

Using ROS Diagnostics in Robotics Operations

LearnApr 29, 2024

How Foxglove's Diagnostics Panel can improve fleet uptime

Hero image for Best Practices for Processing and Analyzing Robotics Data

Best Practices for Processing and Analyzing Robotics Data

LearnJan 22, 2024

Manipulate and understand the data your robots collect

Hero image for Best Practices for Recording and Uploading Robotics Data

Best Practices for Recording and Uploading Robotics Data

LearnJan 15, 2024

Get data off your robots and into the cloud more efficiently

Hero image for How to Use ROS 2 Lifecycle Nodes

How to Use ROS 2 Lifecycle Nodes

LearnNov 21, 2023

Better manage the behavior of your ROS 2 system with lifecycle nodes

Hero image for Installing ROS 2 Iron on Ubuntu

Installing ROS 2 Iron on Ubuntu

LearnNov 14, 2023

Downloading Debian packages to set up the latest ROS 2 release on your Linux machine

Hero image for Sending ROS 2 Message Types Over the Wire

Sending ROS 2 Message Types Over the Wire

LearnAug 28, 2023

Dynamically fetch type descriptions for ROS 2 topics at runtime

Hero image for MCAP vs ROS 1 Bag Index Performance

MCAP vs ROS 1 Bag Index Performance

LearnJun 19, 2023

Comparing performance across indexes, remote storage, and summarization

Hero image for Simulating Robotic Scenarios with ROS 1 and Gazebo

Simulating Robotic Scenarios with ROS 1 and Gazebo

LearnMay 22, 2023

Visualize simulated sensor data with Foxglove

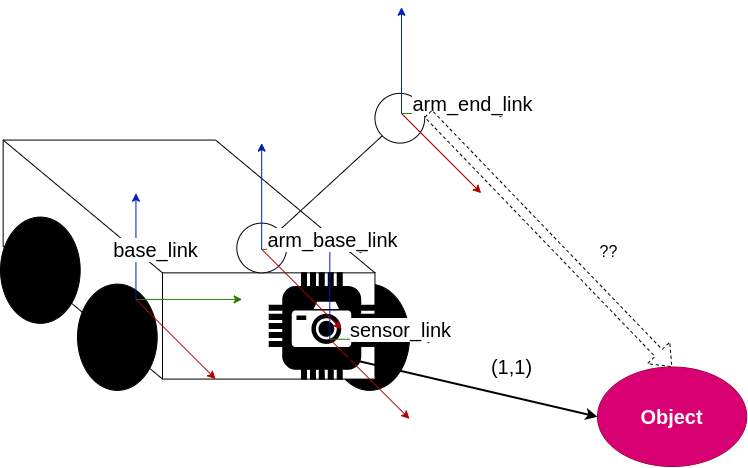
Hero image for Using ROS 1 Transforms to Calculate Object Positions

Using ROS 1 Transforms to Calculate Object Positions

LearnMar 19, 2023

Use the ROS 1 tf2 library to calculate the relative positions of detected objects

Hero image for Using ROS 2 Transforms to Calculate Object Positions

Using ROS 2 Transforms to Calculate Object Positions

LearnFeb 27, 2023

Utilize the ROS 2 tf2 library to compute the relative positions of detected objects.

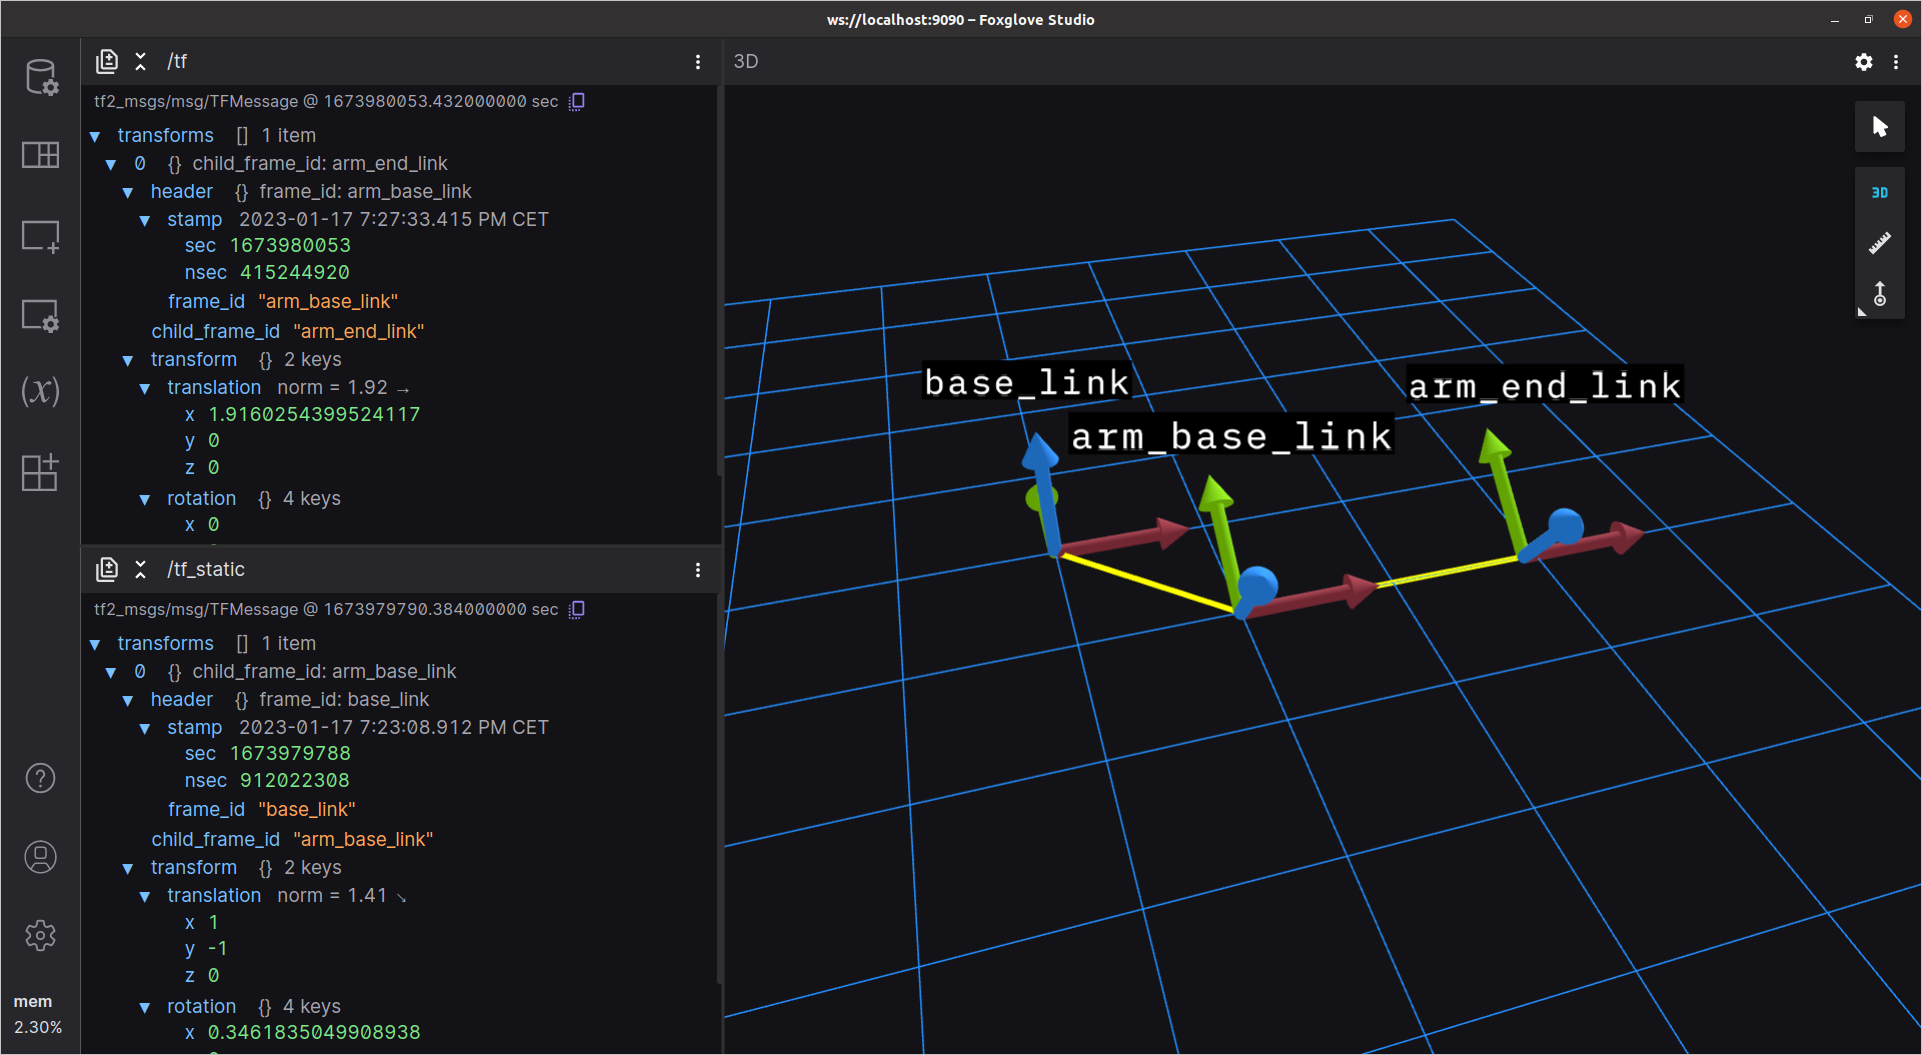
Hero image for Publishing and Visualizing ROS 1 Transforms

Publishing and Visualizing ROS 1 Transforms

LearnJan 23, 2023

Use Foxglove to debug and edit your ROS 1 robot’s transforms.

Hero image for Publishing and Visualizing ROS 2 Transforms

Publishing and Visualizing ROS 2 Transforms

LearnJan 18, 2023

Utilize Foxglove to debug and modify your ROS 2 robot’s transforms efficiently.

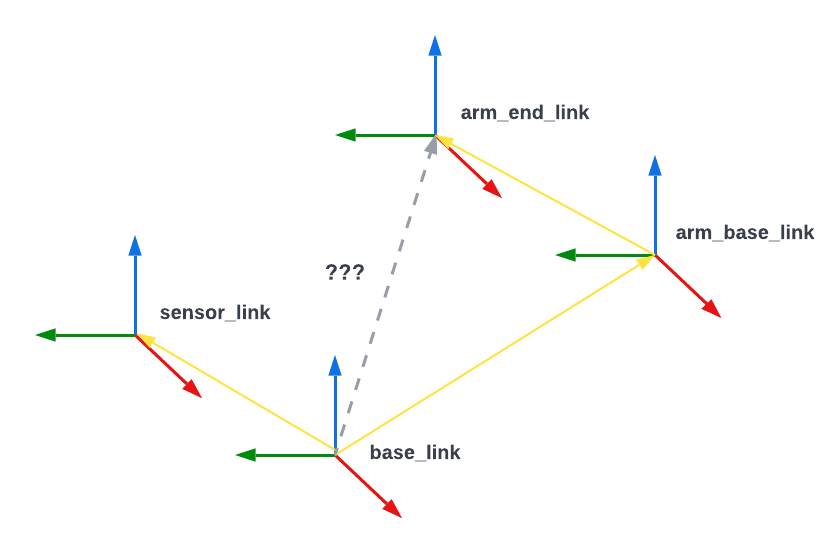
Hero image for Understanding ROS Transforms

Understanding ROS Transforms

LearnDec 20, 2022

Defining how objects in a robot's world relate to each other

Hero image for Implementing a macOS Search Plug-In for Robotics Data

Implementing a macOS Search Plug-In for Robotics Data

LearnDec 6, 2022

How we built a Spotlight Importer for MCAP files using Swift

Hero image for How to Use ROS 1 Launch Files

How to Use ROS 1 Launch Files

LearnOct 30, 2022

Executing and configuring multiple ROS 1 nodes at once

Hero image for How to Use ROS 1 Parameters

How to Use ROS 1 Parameters

LearnOct 2, 2022

Configure your ROS nodes at startup to customize their behavior

Hero image for Creating ROS 1 Actions

Creating ROS 1 Actions

LearnAug 22, 2022

Coordinate open-ended communication between your ROS 1 nodes

Hero image for Creating ROS 1 Services

Creating ROS 1 Services

LearnAug 15, 2022

Make discrete requests between ROS 1 nodes for one-off tasks