Blog

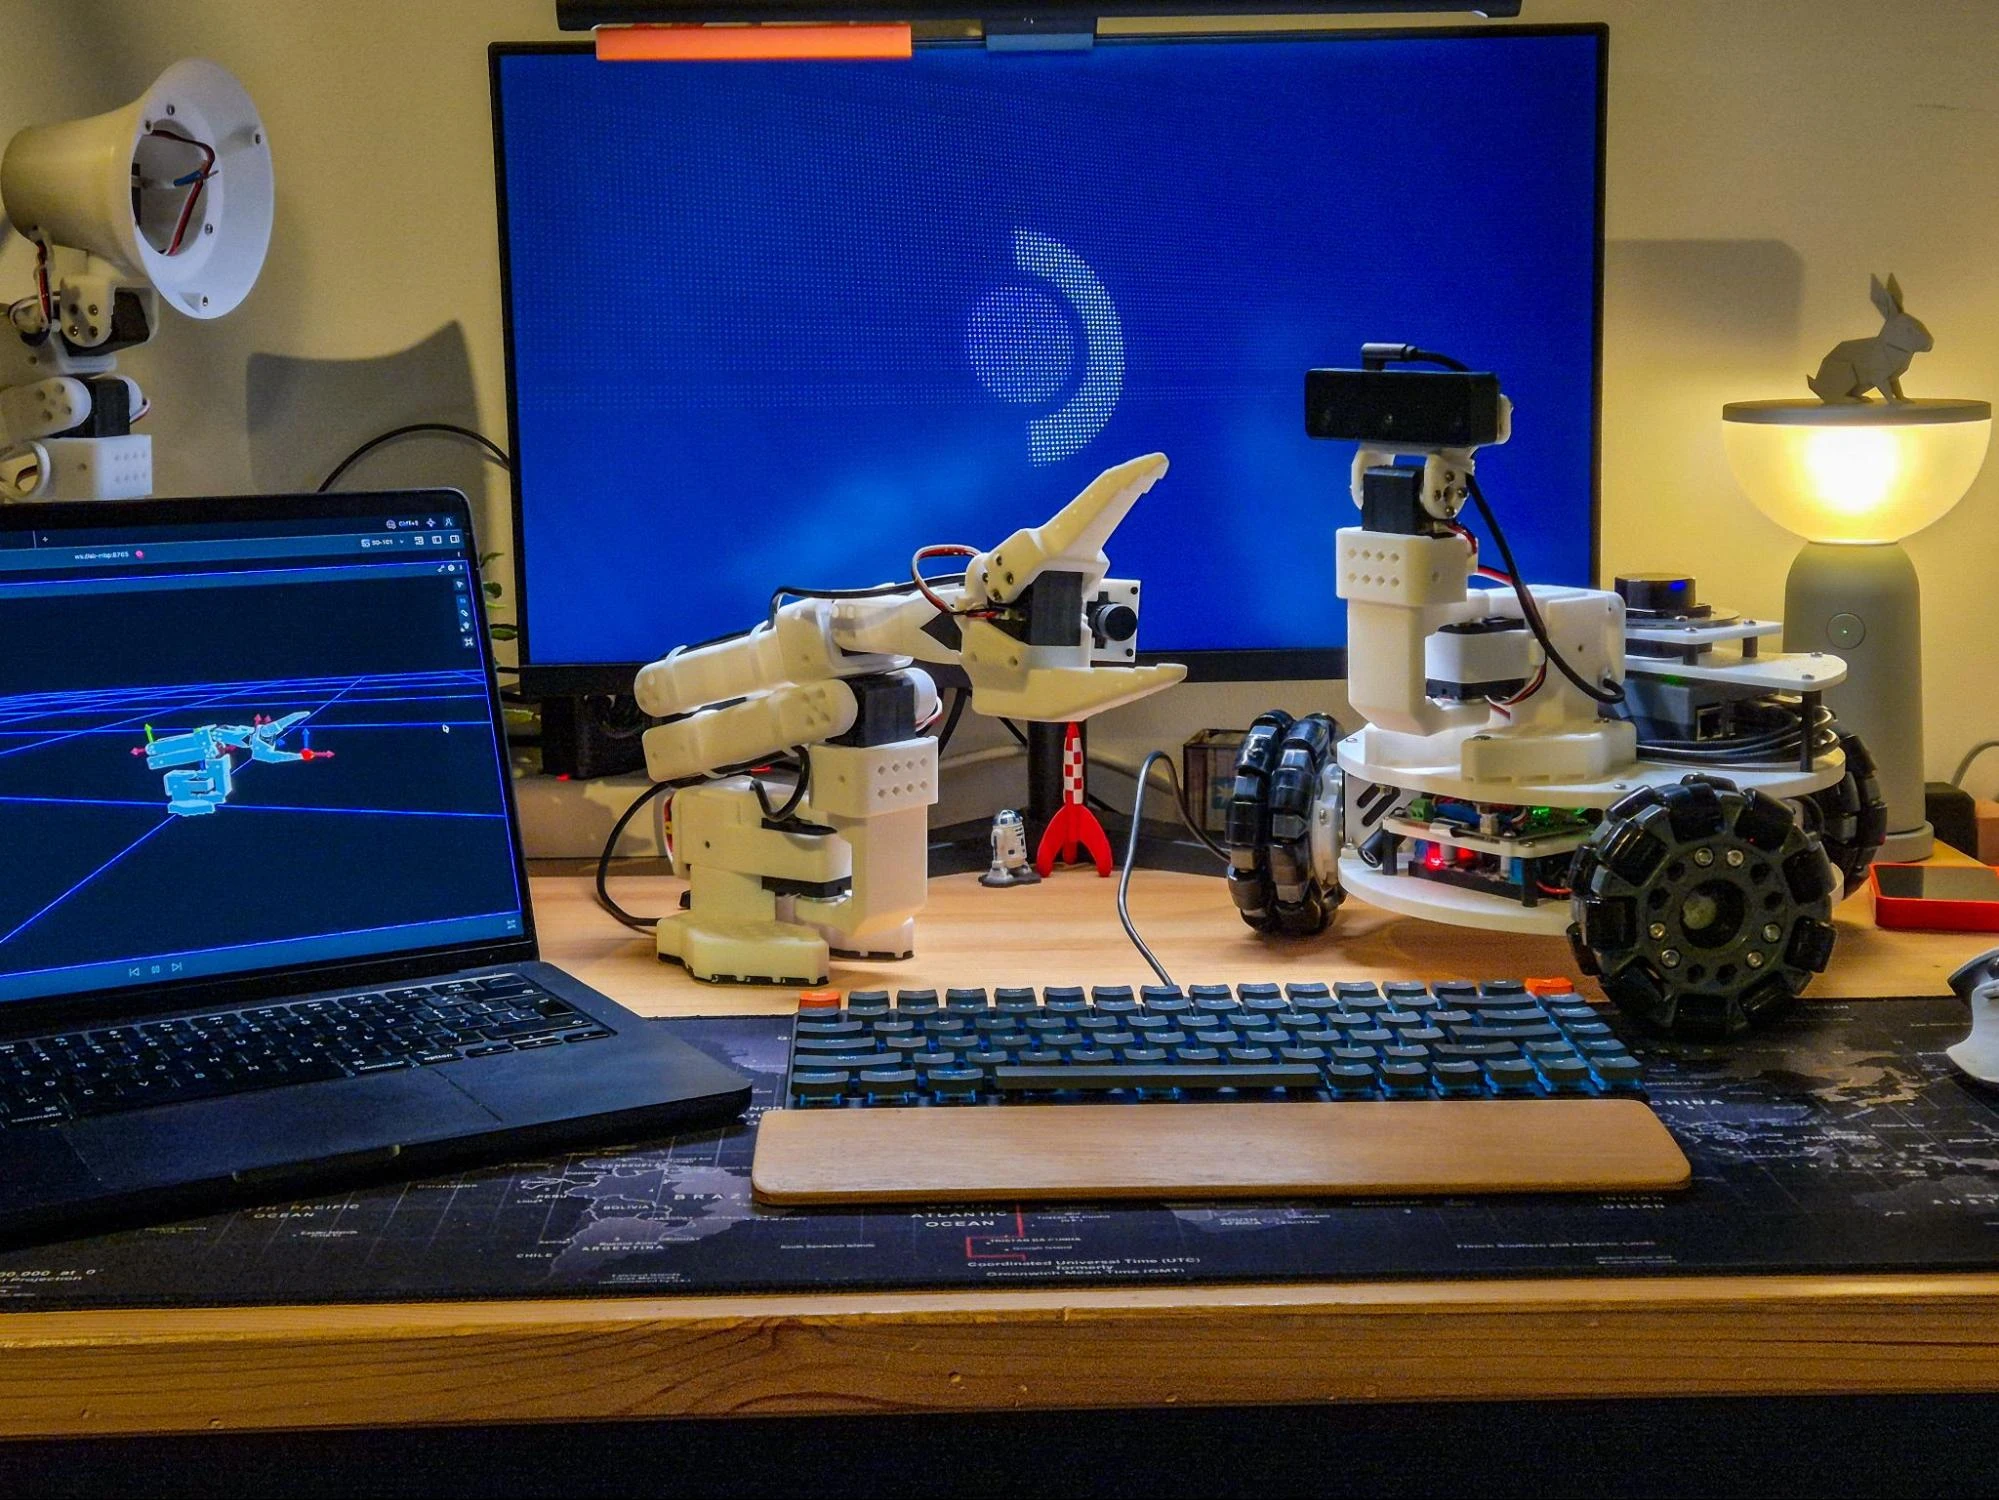
Desk setup with an SO-101 robot arm, a LeKiwi mobile robot, and Foxglove showing the arm on a laptop

Using Foxglove as an SO-101 Simulator

LearnSep 20, 2026

While assembling an SO-101 arm, I used ROS 2 Control mock mode and Foxglove's 3D panel as a stand-in simulator - building IK teleop, manual joint control, and self-collision checking before the real hardware was ready.

The LeKiwi mobile robot on a green carpet, with its pan-tilt depth camera, 360° LiDAR, and omni wheels

Autonomous Navigation with LeKiwi — Part 2

LearnJul 27, 2026

A follow-up to Autonomous Navigation with LeKiwi: collision protection for teleop via collision_monitor, a waypoint recorder for patrol routes controlled from Foxglove, and keepout plus speed-limited zones that Nav2 routes around or slows down in.

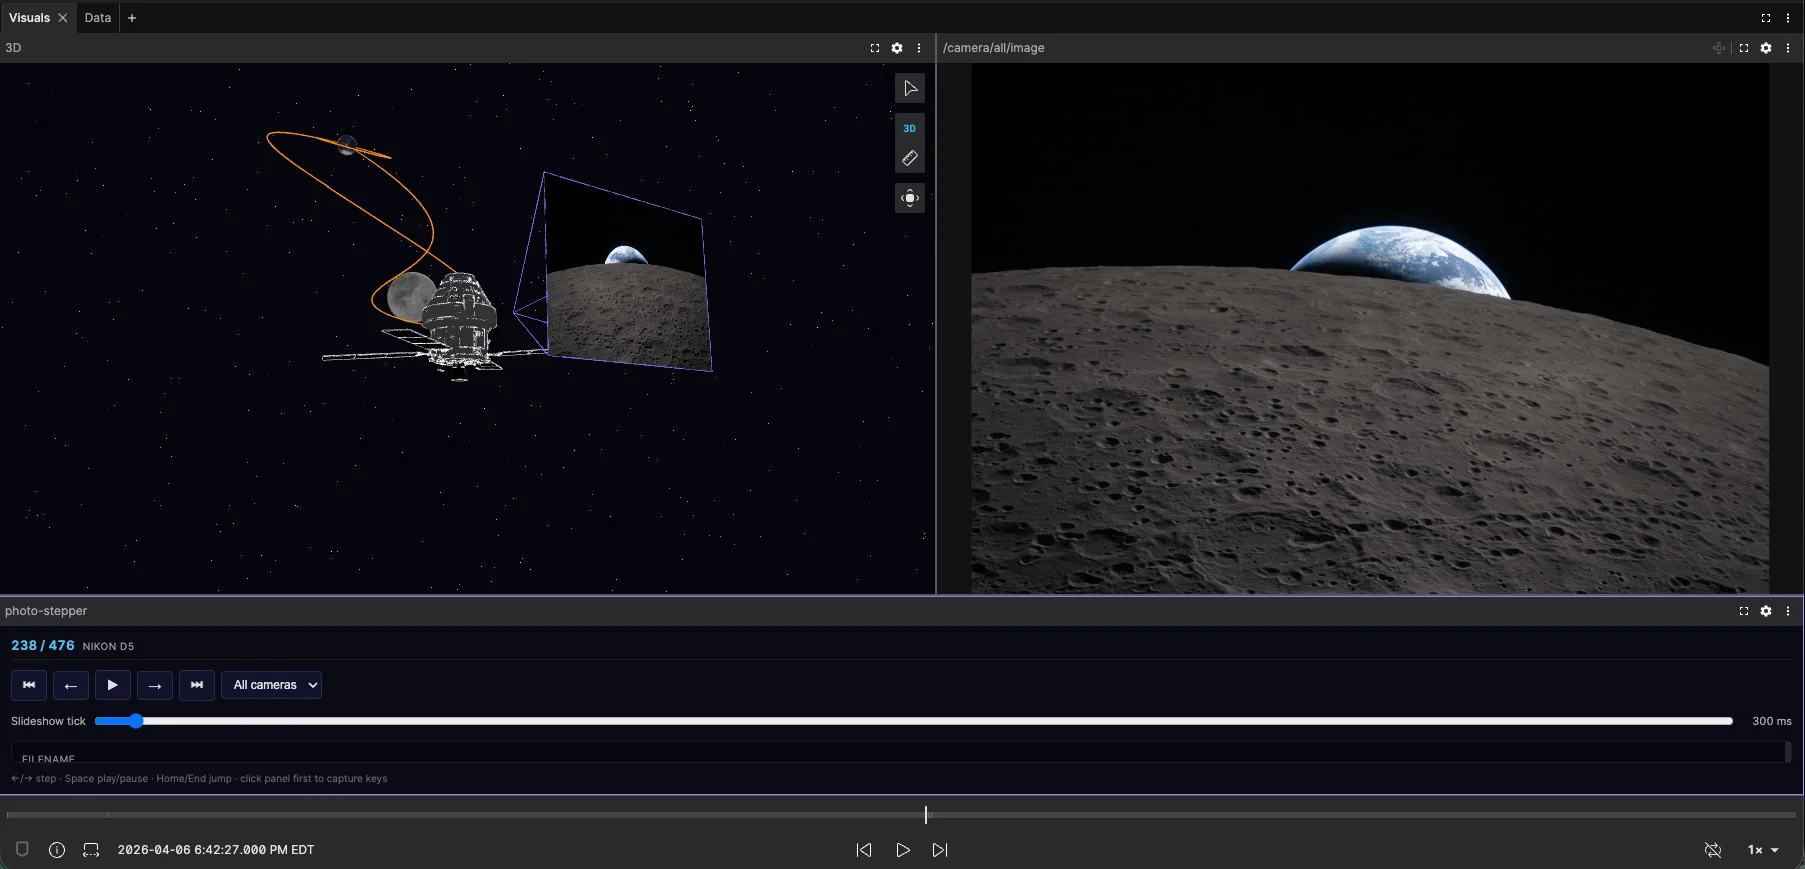
Orion's trajectory around the Moon visualized in the Foxglove 3D panel

Visualizing the Artemis II Mission

LearnJul 20, 2026

In April 2026, four astronauts flew around the Moon for the first time in over fifty years. I built a Foxglove visualization of the Artemis II mission: Orion's real trajectory through inertial space in 3D, 476 mission photos synchronized to the timeline, and a custom photo-stepper extension that turns the whole thing into a navigable album.

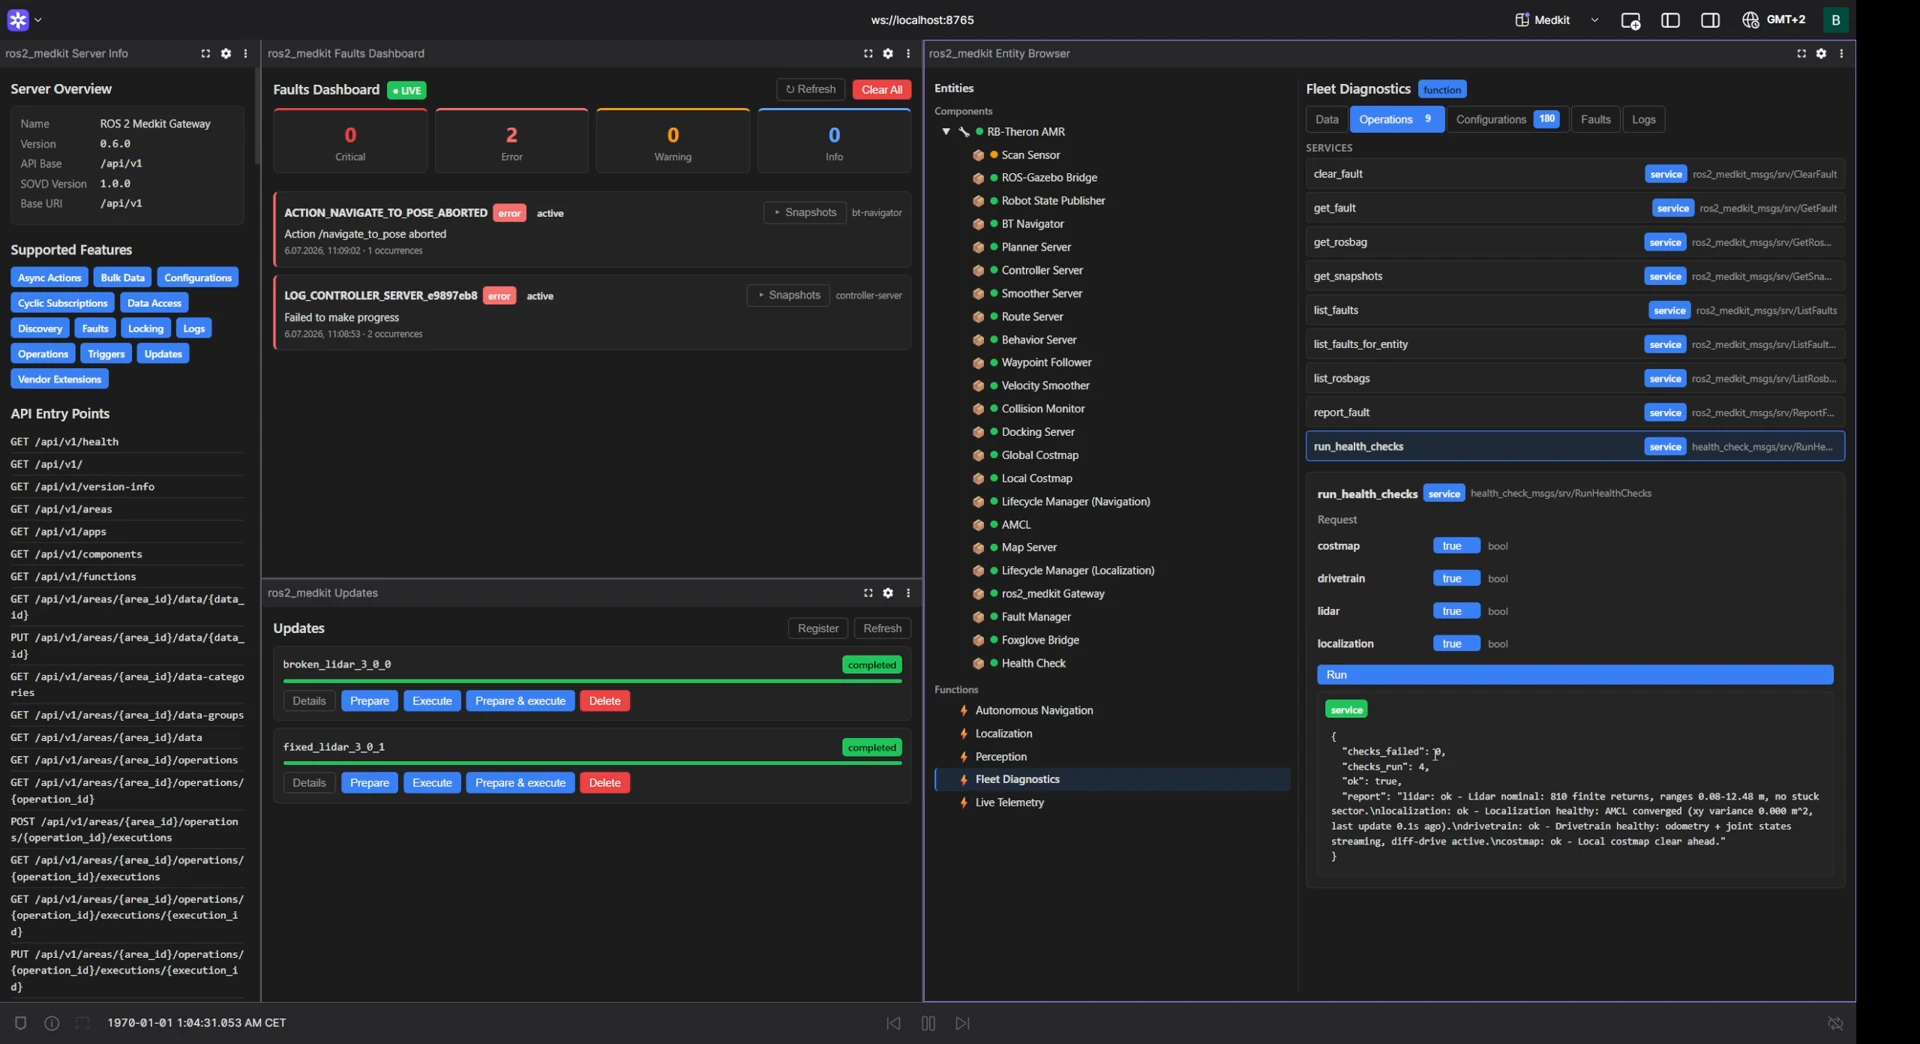
ros2_medkit Foxglove extension in action

When you can't reach the robot: SOVD diagnostics and OTA updates in Foxglove via the ros2_medkit extension

LearnJul 15, 2026

When your connection to a warehouse robot drops, ros2_medkit brings SOVD diagnostics, on-robot failure capture, and OTA repair actions into Foxglove panels—so you can see the problem and fix it in one application.

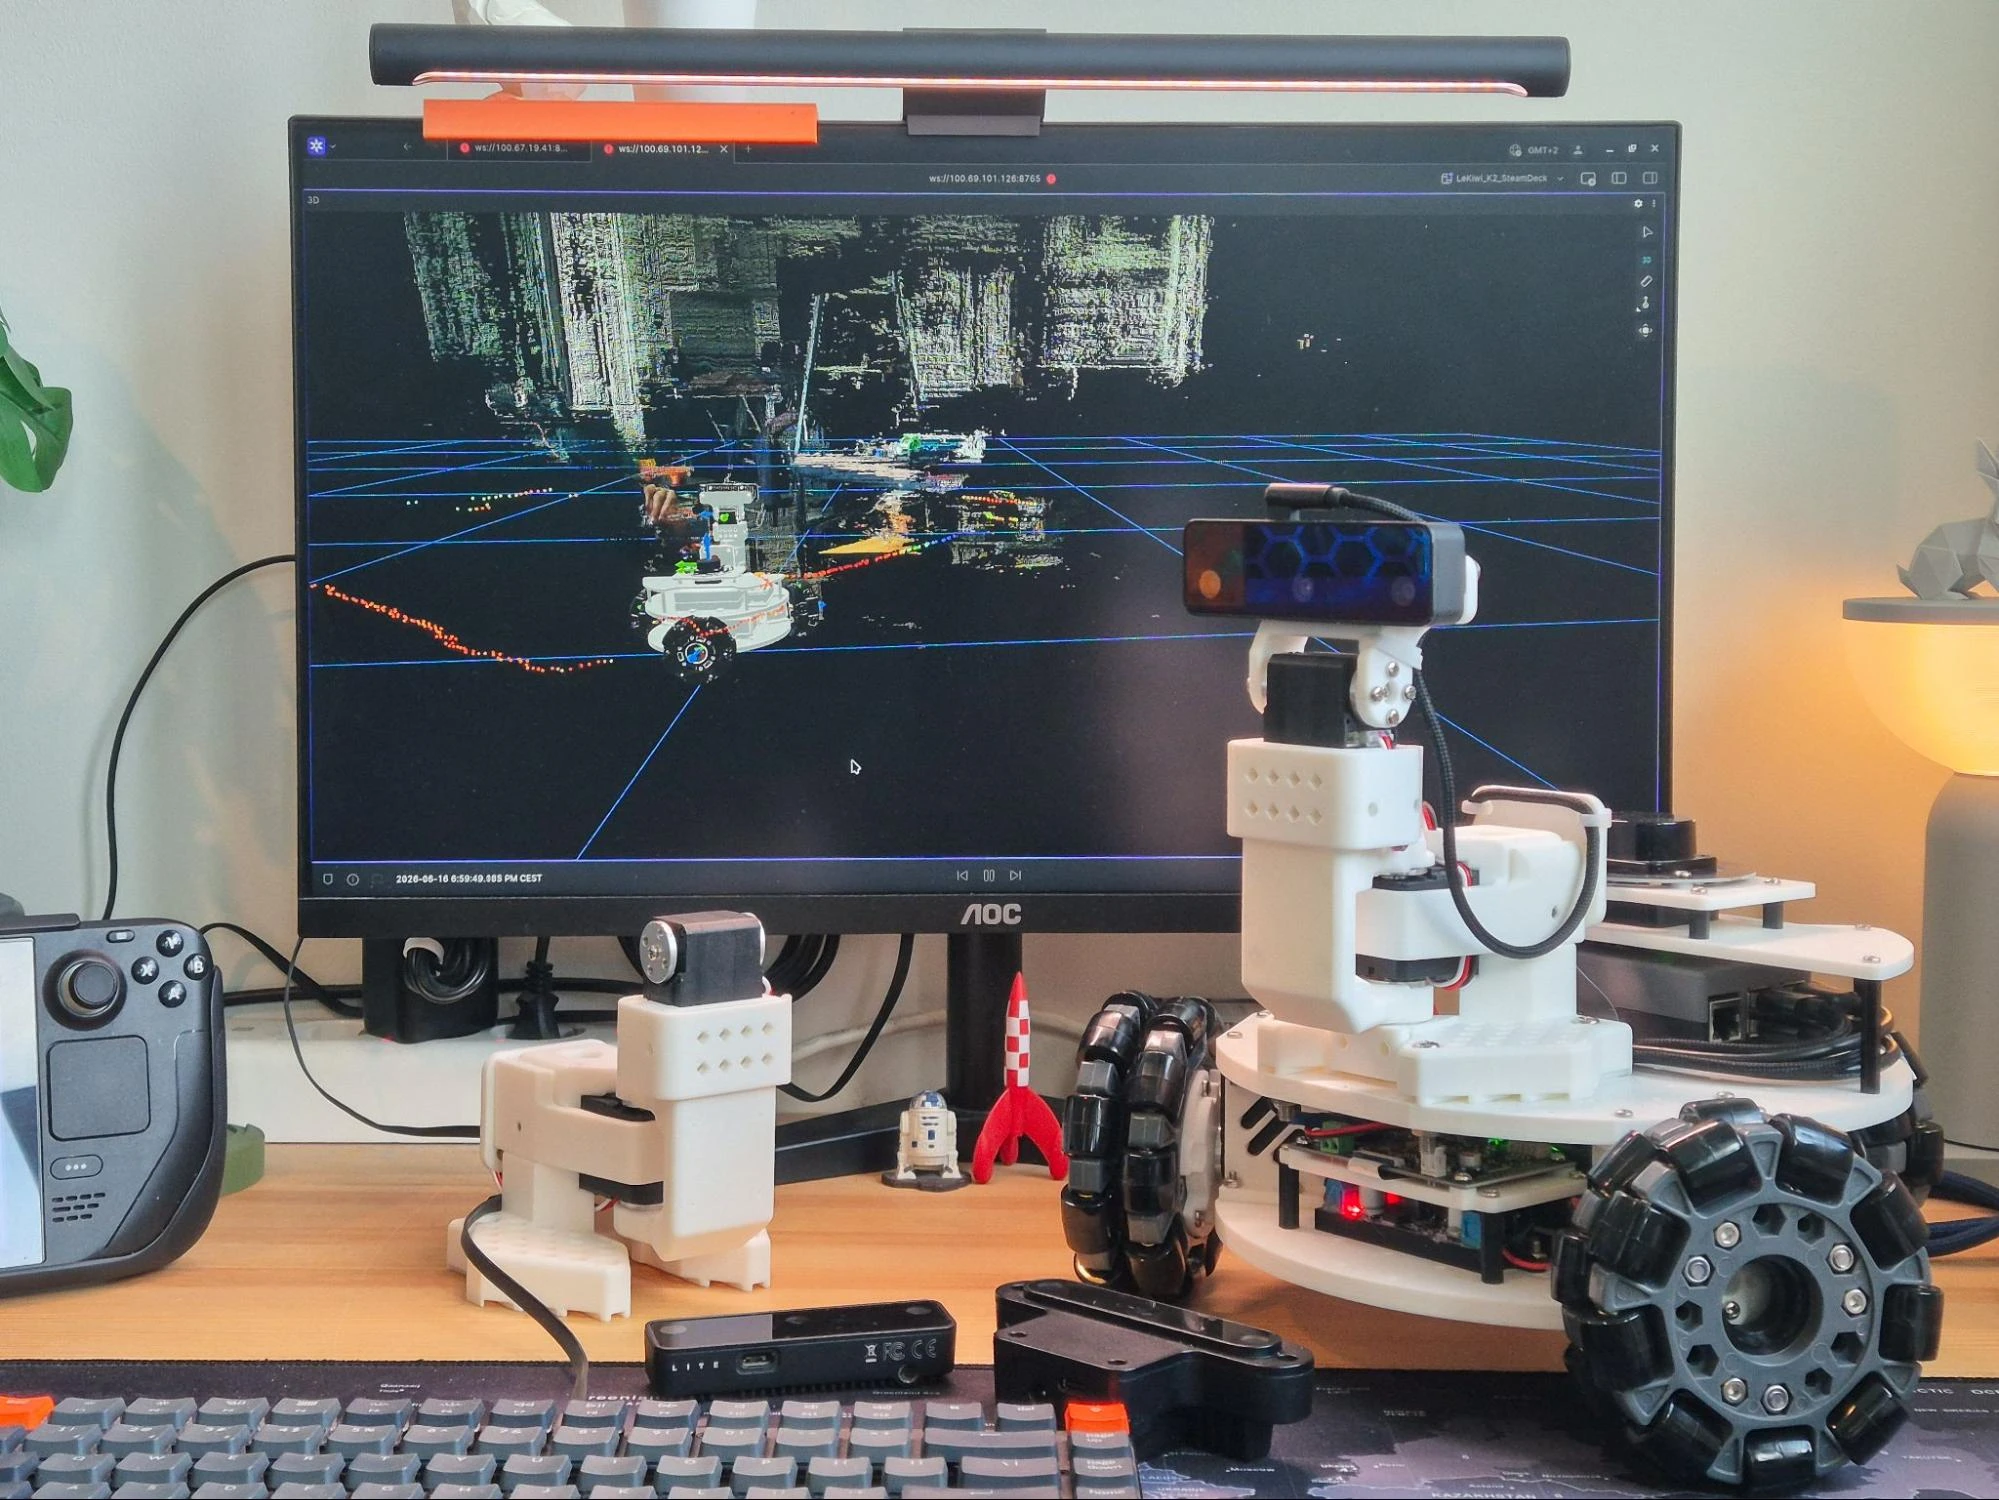
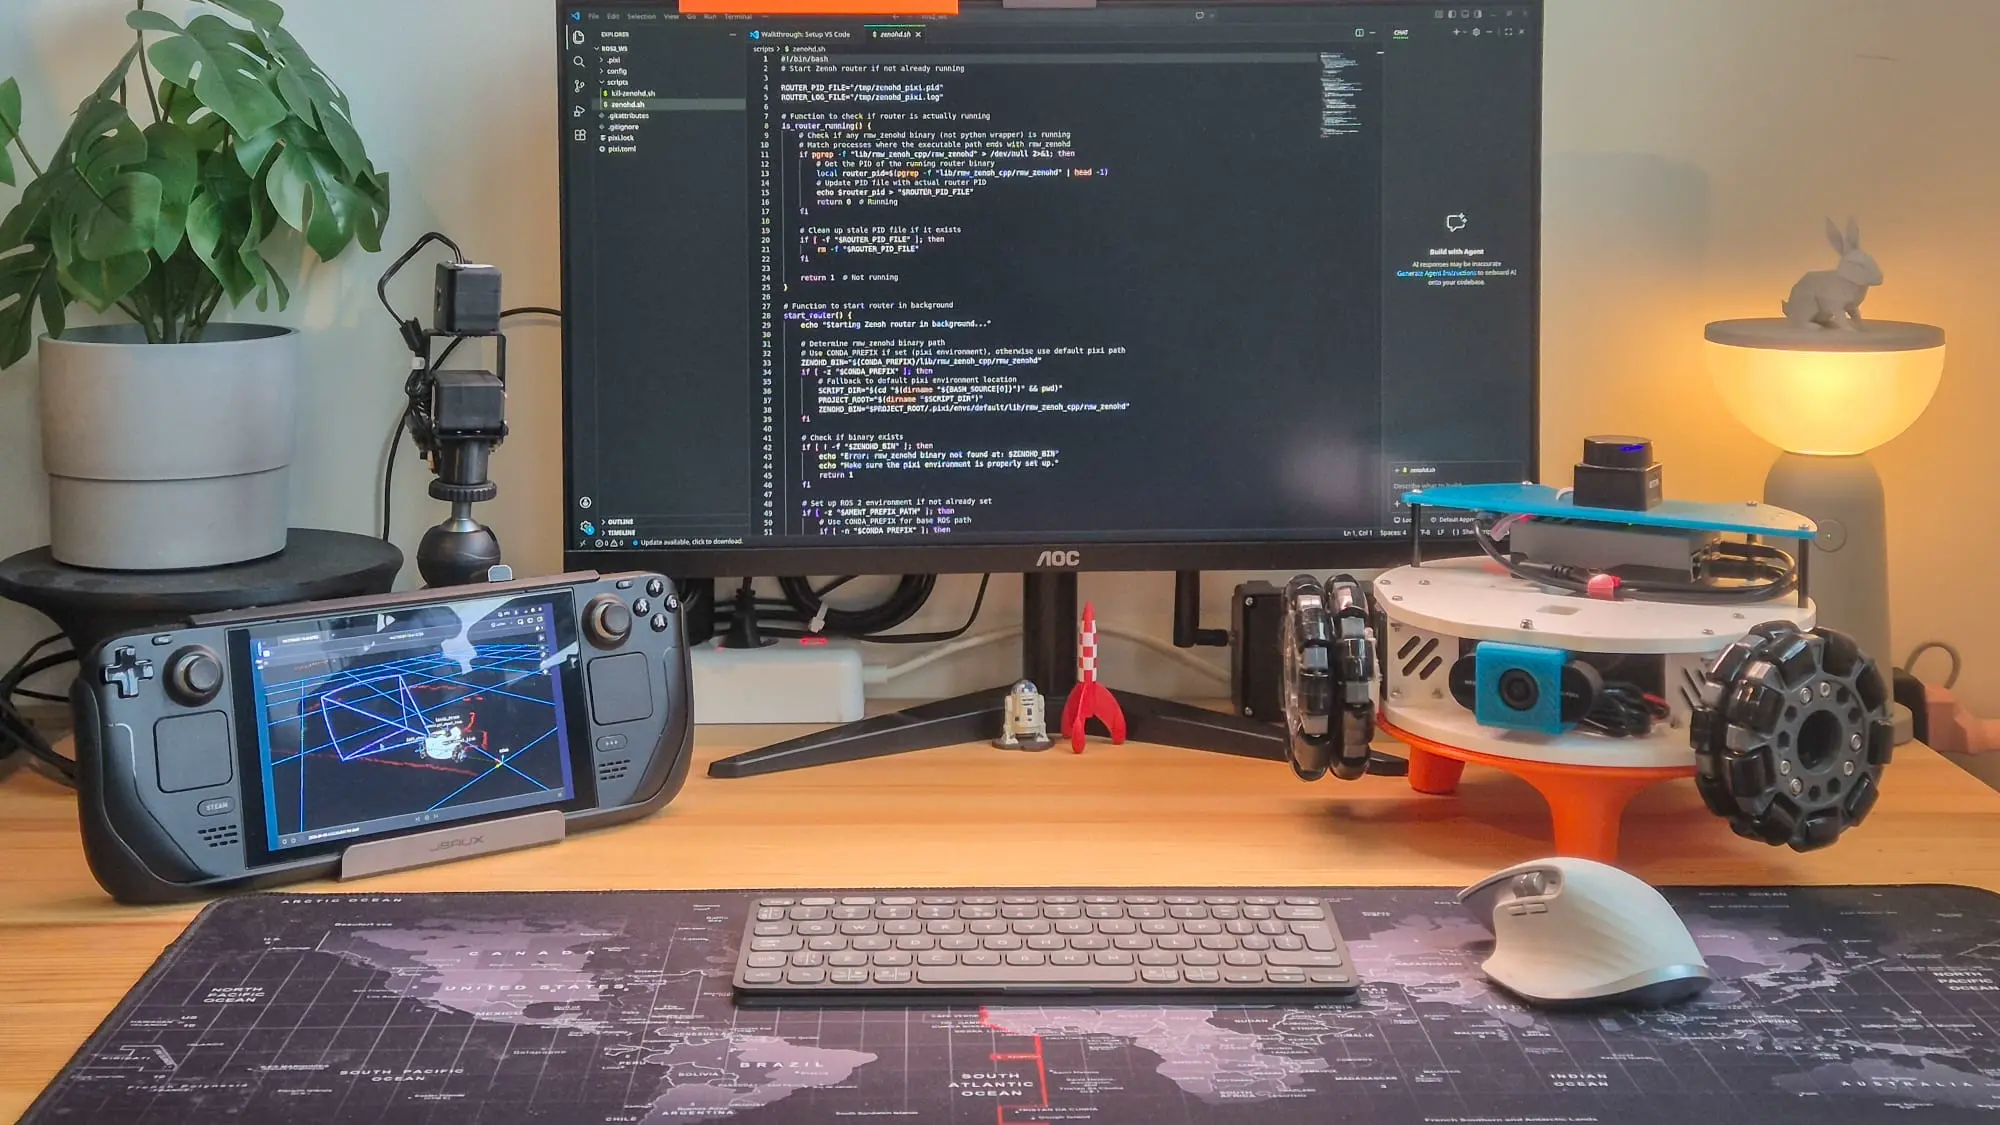
The LeKiwi robot with its OAK-D S2 pan-tilt camera on a desk, next to a monitor showing a pointcloud in Foxglove and a Steam Deck

Visualizing Depth Maps and Pointclouds from the OAK-D S2 in Foxglove

LearnJun 18, 2026

How I integrated a Luxonis OAK-D S2 stereo depth camera into my LeKiwi robot's ROS 2 stack — configuring the depthai-ros driver for low bandwidth, compressing pointclouds with Cloudini, and visualizing RGB images, depth maps, and pointclouds in Foxglove's 3D panel.
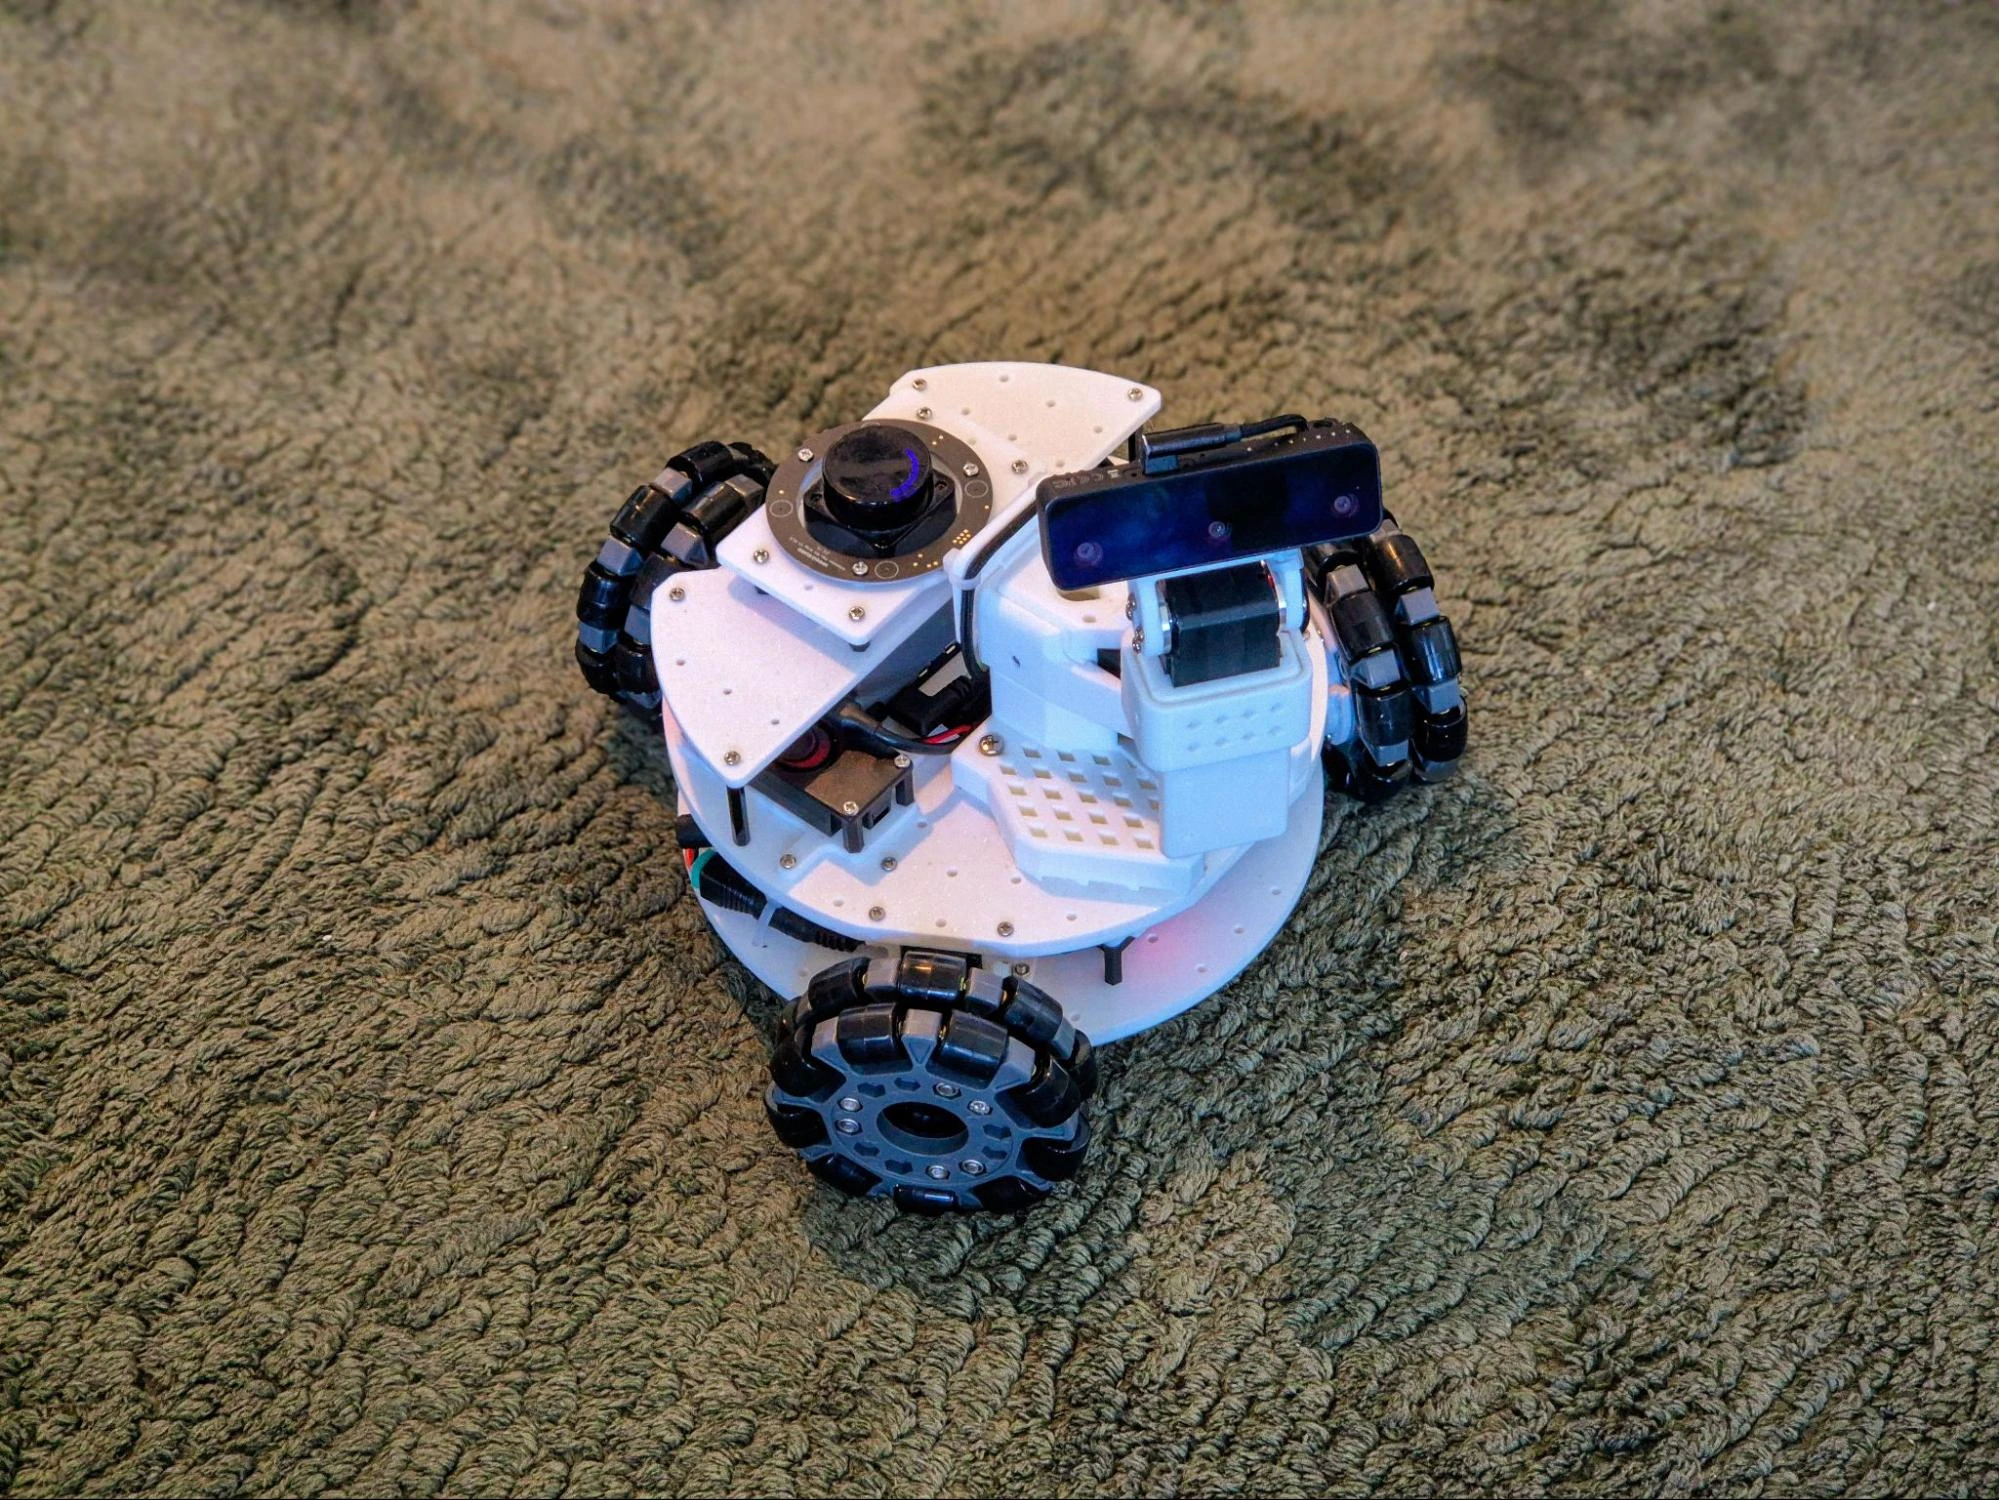
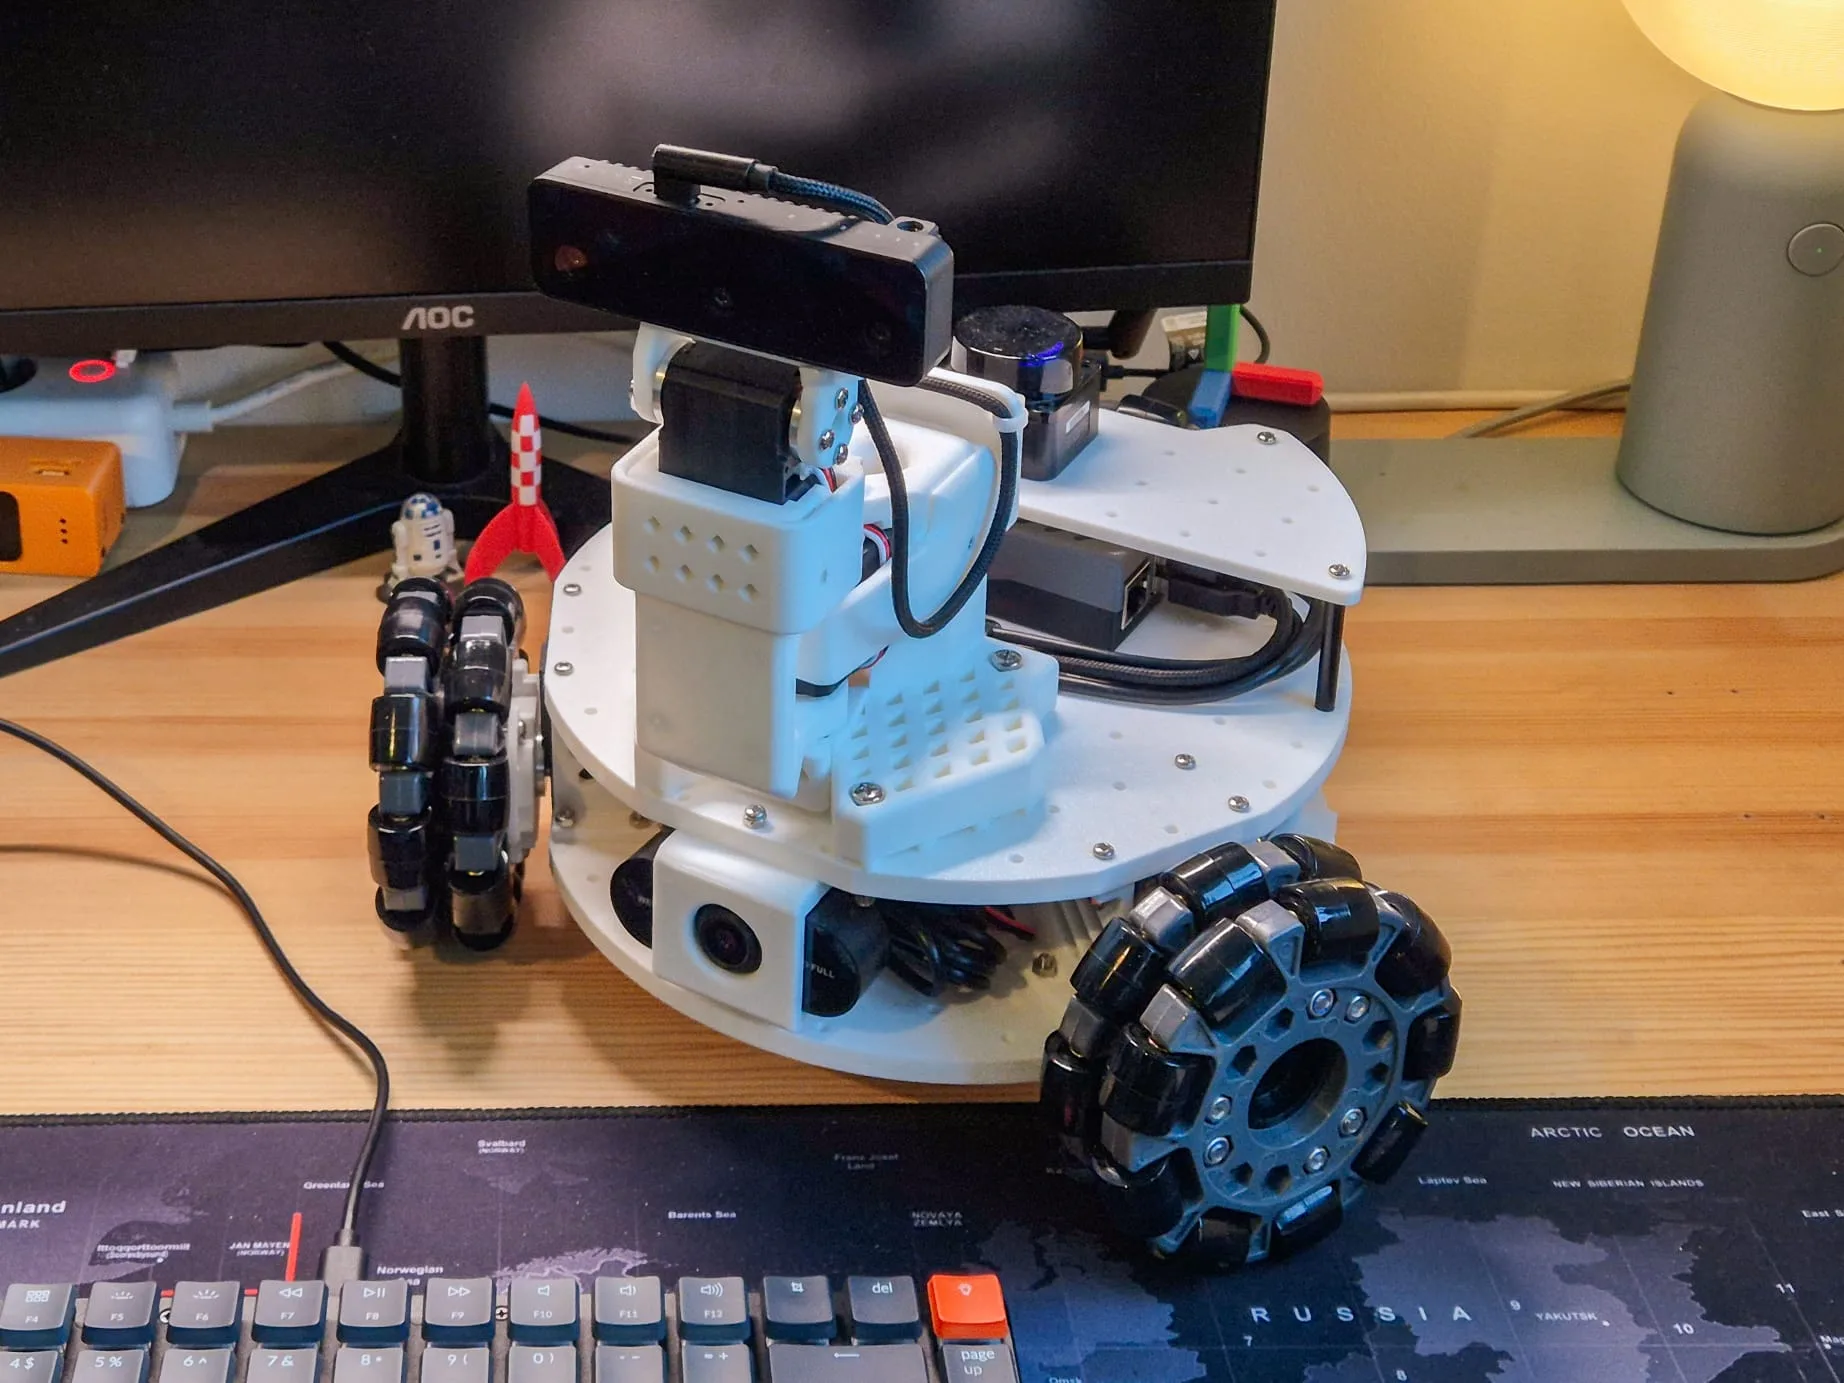
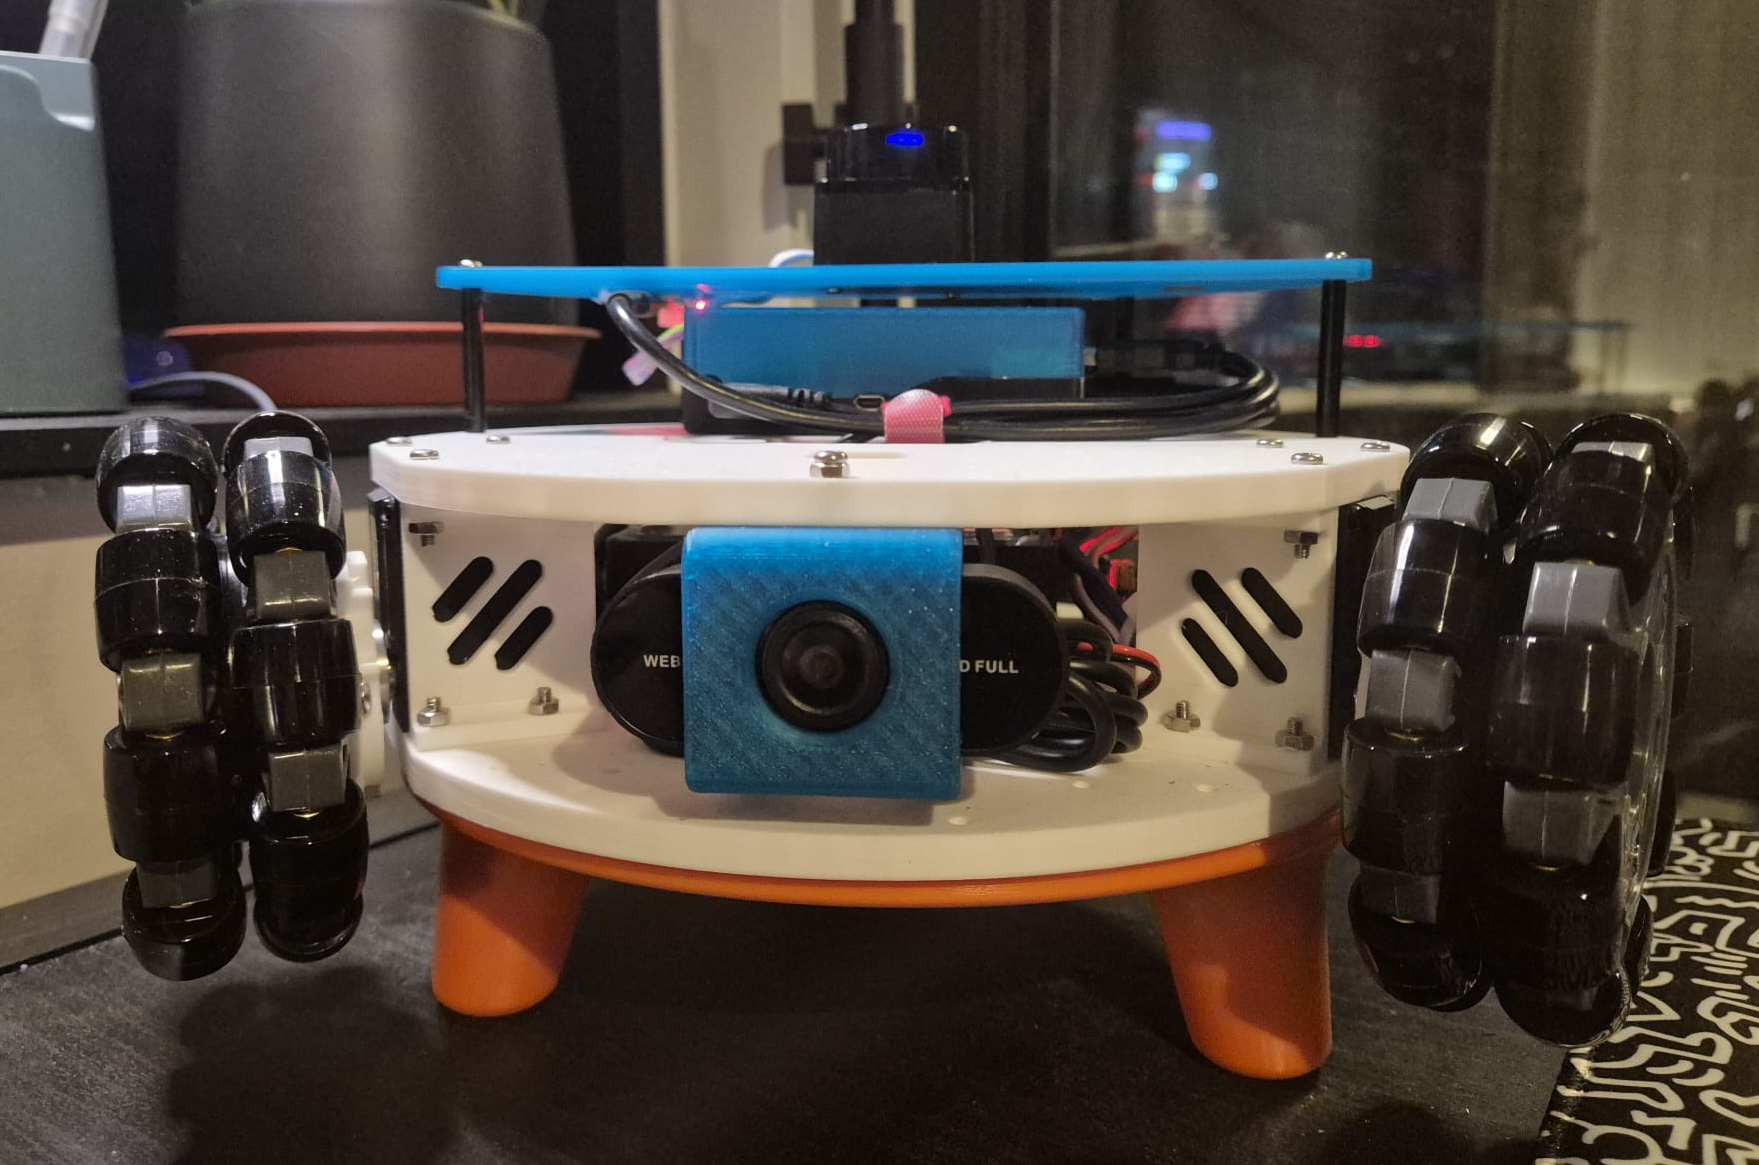
The LeKiwi mobile robot on a desk, with its pan-tilt camera, 360° LiDAR, and omni wheels

Autonomous Navigation with LeKiwi and Nav2

LearnJun 9, 2026

How I added autonomous navigation to my LeKiwi robot with Nav2 — covering LiDAR filtering, mapping with slam_toolbox, localization with AMCL, and configuring Nav2 for a holonomic base, all visualized and controlled from Foxglove.

A Steam Deck running Foxglove

Teleoperating the LeKiwi Robot from a Steam Deck

LearnApr 28, 2026

Learn how to turn a Steam Deck into a portable all-in-one LeKiwi controller and Foxglove monitoring station using Pixi, Distrobox, and ROS 2.

Calibrating a monocular camera for the LeKiwi robot using ROS 2

Calibrating a monocular camera for the LeKiwi robot using ROS 2

LearnMar 4, 2026

This article details the process of calibrating a USB webcam for the LeKiwi robot, modifying the standard ROS 2 camera calibration process to run headless without a display, using terminal logging and automatic result saving.

Hero image for Upgrading the LeKiwi into a LiDAR-equipped explorer

Upgrading the LeKiwi into a LiDAR-equipped explorer

LearnFeb 7, 2026

Upgrading LeKiwi robot with a 2D LiDAR and ROS 2, transforming it into a low-cost open-source autonomous platform

Hero image for Turning a VLP‑16 Into a “Spherical” Scanner

Turning a VLP‑16 Into a “Spherical” Scanner

LearnJan 31, 2026

How a secondhand VLP‑16, one extra mechanical axis, and encoder-based deskewing turned into a cave-mapping learning project

Hero image for Working with scenes and Pointclouds.

Working with scenes and Pointclouds.

LearnAug 25, 2025

Working with scenes and Pointclouds.

Hero image for Converting the EuRoC MAV Dataset to MCAP and visualizing SLAM using Foxglove.

Converting the EuRoC MAV Dataset to MCAP and visualizing SLAM using Foxglove.

LearnAug 4, 2025

Converting the EuRoC MAV Dataset to MCAP and visualizing SLAM using Foxglove.

Hero image for Comparing ML training using the Foxglove SDK.

Comparing ML training using the Foxglove SDK.

LearnJul 21, 2025

Comparing ML training using the Foxglove SDK.

Hero image for Visualizing Open X-Embodiment Dataset in Foxglove.

Visualizing Open X-Embodiment Dataset in Foxglove.

LearnJul 10, 2025

Visualizing Open X-Embodiment Dataset in Foxglove.

Hero image for Visualizing LeRobot (SO-100) using Foxglove

Visualizing LeRobot (SO-100) using Foxglove

LearnJun 22, 2025

Visualizing LeRobot (SO-100) using Foxglove

Hero image for Converting the LAFAN1 Retargeting dataset to MCAP.

Converting the LAFAN1 Retargeting dataset to MCAP.

LearnMay 28, 2025

Converting the LAFAN1 Retargeting dataset to MCAP.

Hero image for Converting the Argoverse 2 dataset to MCAP.

Converting the Argoverse 2 dataset to MCAP.

LearnMay 26, 2025

Converting the Argoverse 2 dataset to MCAP.

Hero image for Record once, read forever.

Record once, read forever.

LearnMay 8, 2025

MCAP and the Foxglove SDK.