Blog

Hero image for Visualizing LeRobot (SO-100) using Foxglove

Visualizing LeRobot (SO-100) using Foxglove

LearnJun 22, 2025

Visualizing LeRobot (SO-100) using Foxglove

Hero image for Converting the LAFAN1 Retargeting dataset to MCAP.

Converting the LAFAN1 Retargeting dataset to MCAP.

LearnMay 28, 2025

Converting the LAFAN1 Retargeting dataset to MCAP.

Hero image for Converting the Argoverse 2 dataset to MCAP.

Converting the Argoverse 2 dataset to MCAP.

LearnMay 26, 2025

Converting the Argoverse 2 dataset to MCAP.

Hero image for Record once, read forever.

Record once, read forever.

LearnMay 8, 2025

MCAP and the Foxglove SDK.

Hero image for ROS 2 composable nodes.

ROS 2 composable nodes.

LearnMar 13, 2025

Optimizing ROS 2 communication: reducing latency with composableNodes.

Hero image for How robots think: processes in a computer.

How robots think: processes in a computer.

LearnFeb 2, 2025

Understanding the digital brain in robots.

Hero image for Converting the WayveScenes101 dataset to MCAP.

Converting the WayveScenes101 dataset to MCAP.

LearnDec 10, 2024

MCAP is an open source container file format for multimodal log data.

Hero image for Converting the Waymo Open dataset to MCAP.

Converting the Waymo Open dataset to MCAP.

LearnNov 11, 2024

Visualized using Foxglove.

Hero image for Autonomous robot navigation and Nav2: The first steps.

Autonomous robot navigation and Nav2: The first steps.

LearnOct 9, 2024

Your first steps with Nav2.

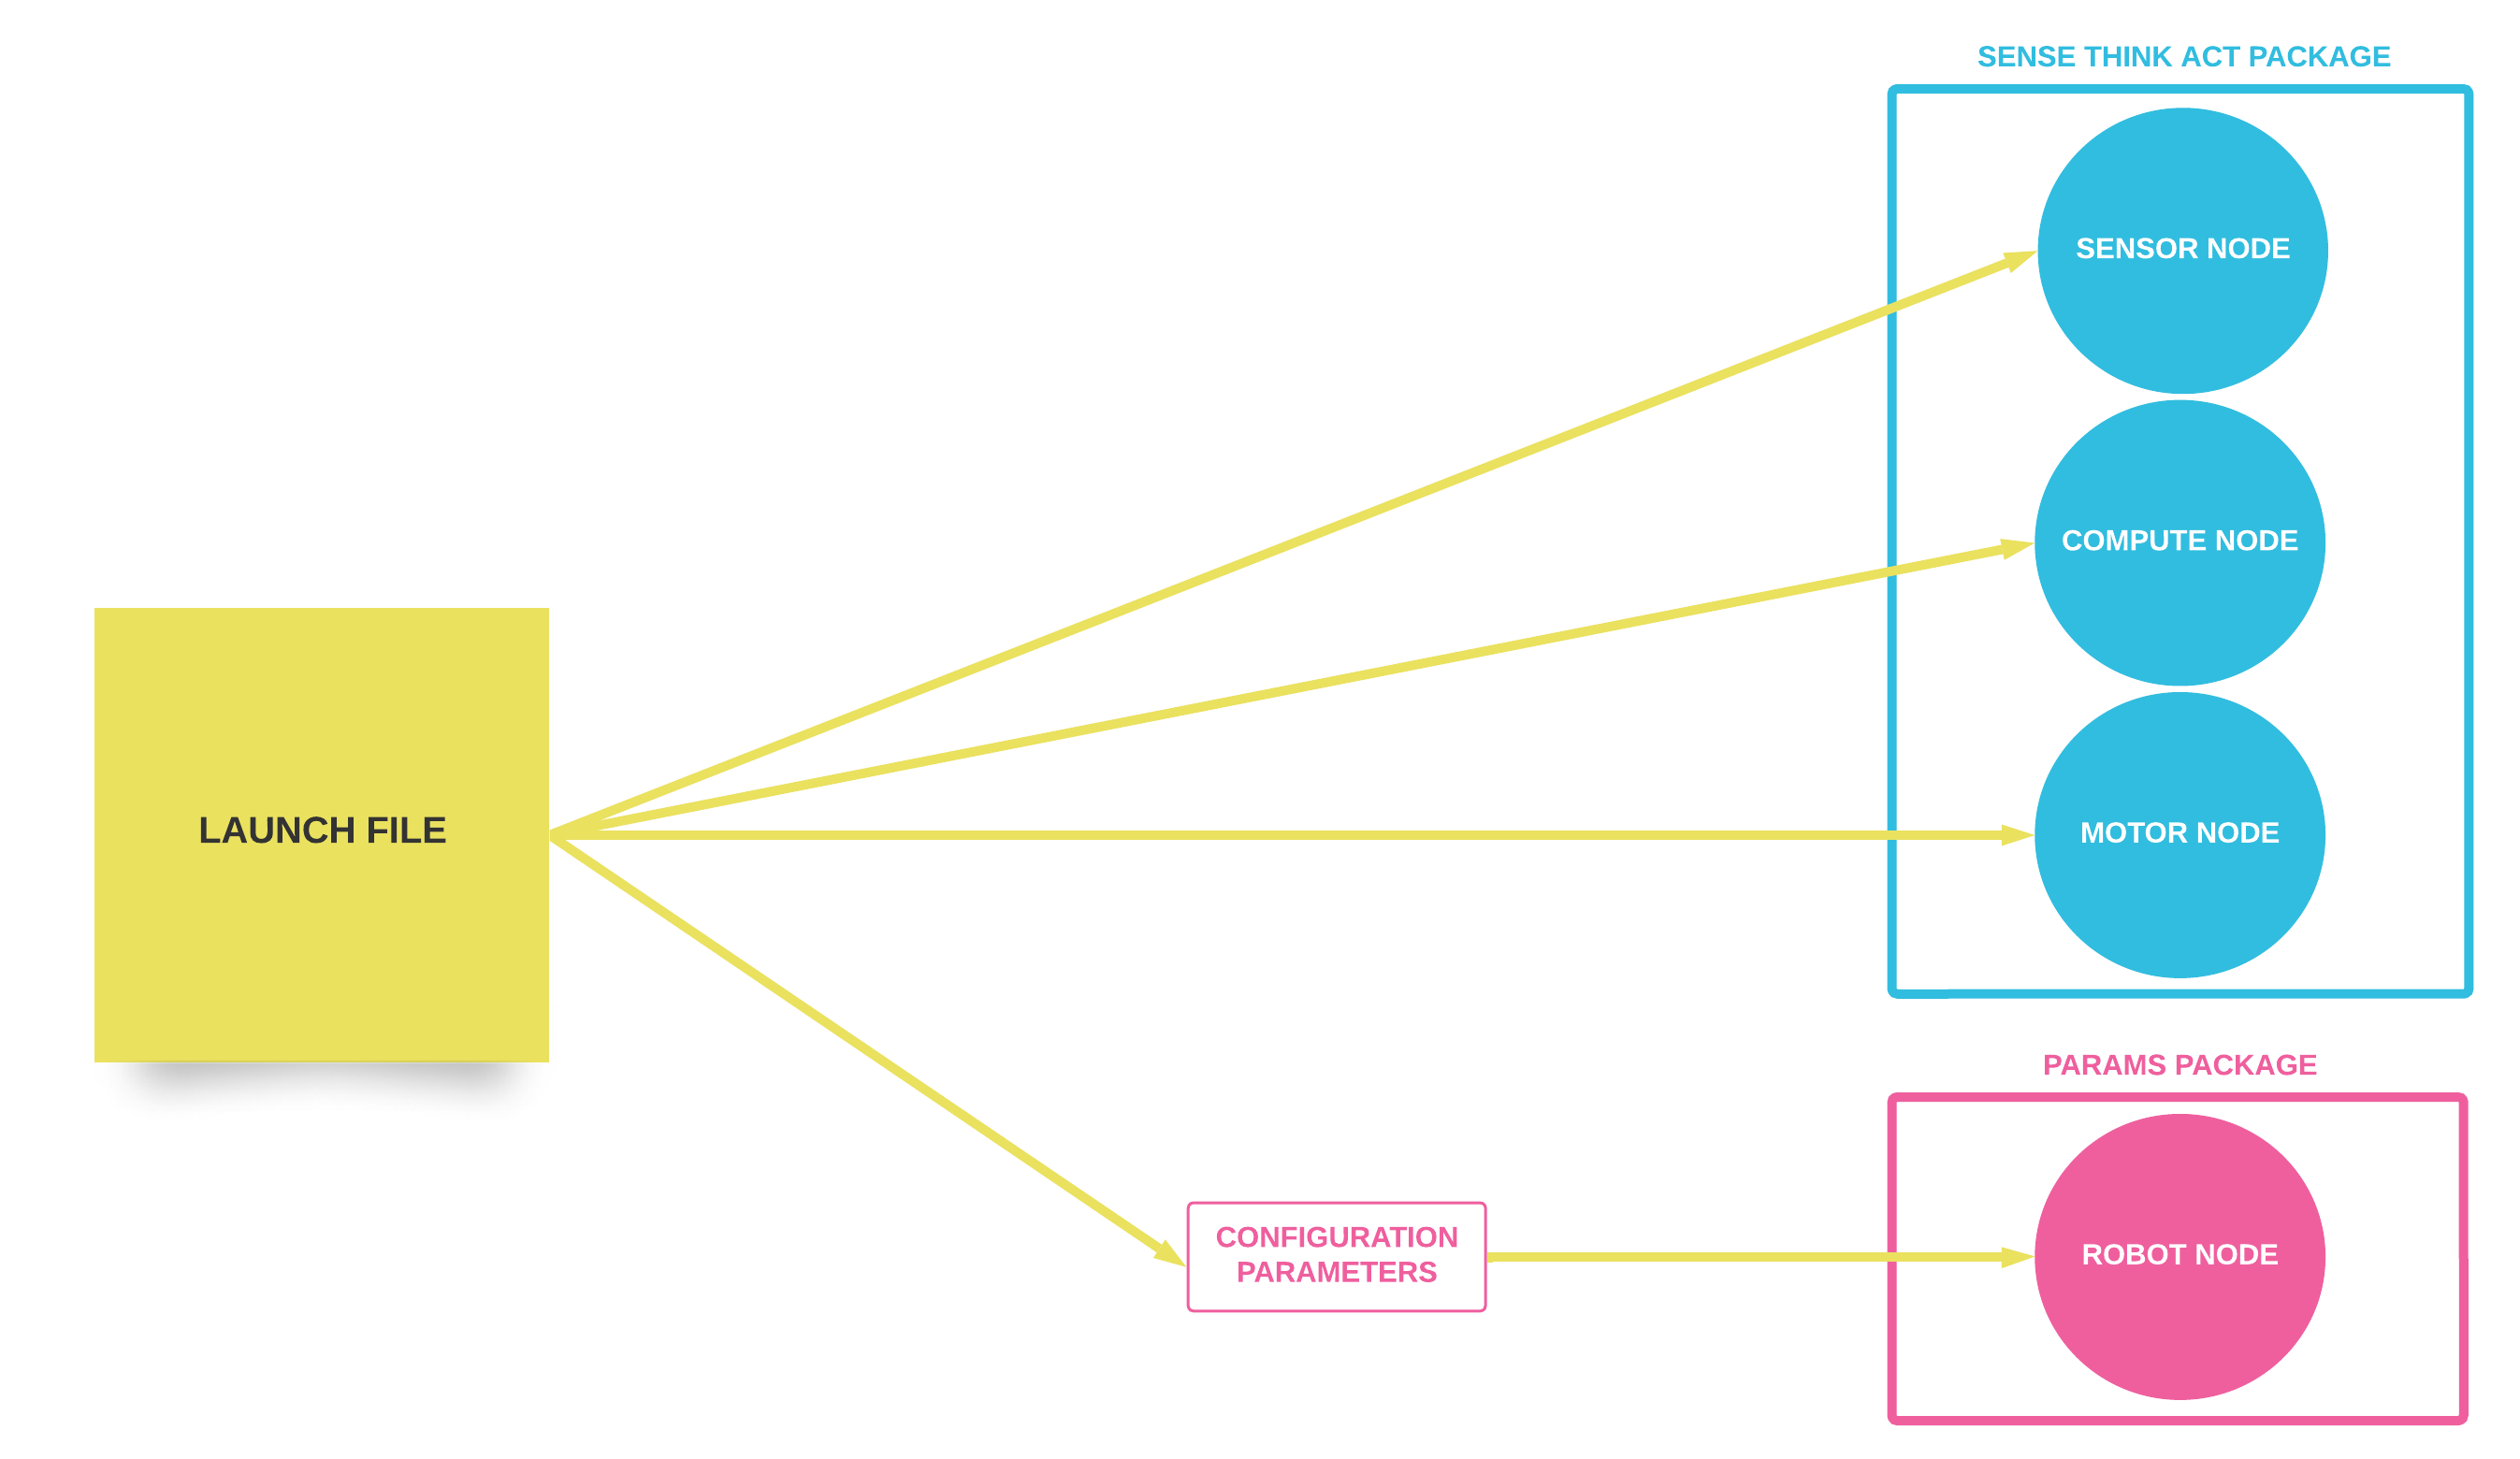
Hero image for How to Use ROS 2 Launch Files

How to Use ROS 2 Launch Files

LearnAug 26, 2024

Executing and configuring multiple ROS 2 nodes at once

Hero image for The first steps when using Rust with ROS 2

The first steps when using Rust with ROS 2

LearnAug 8, 2024

A step-by-step guide to using Rust with ROS 2

Hero image for Understanding MCAP chunk size and compression

Understanding MCAP chunk size and compression

LearnJul 30, 2024

Optimize your recording and playback performance

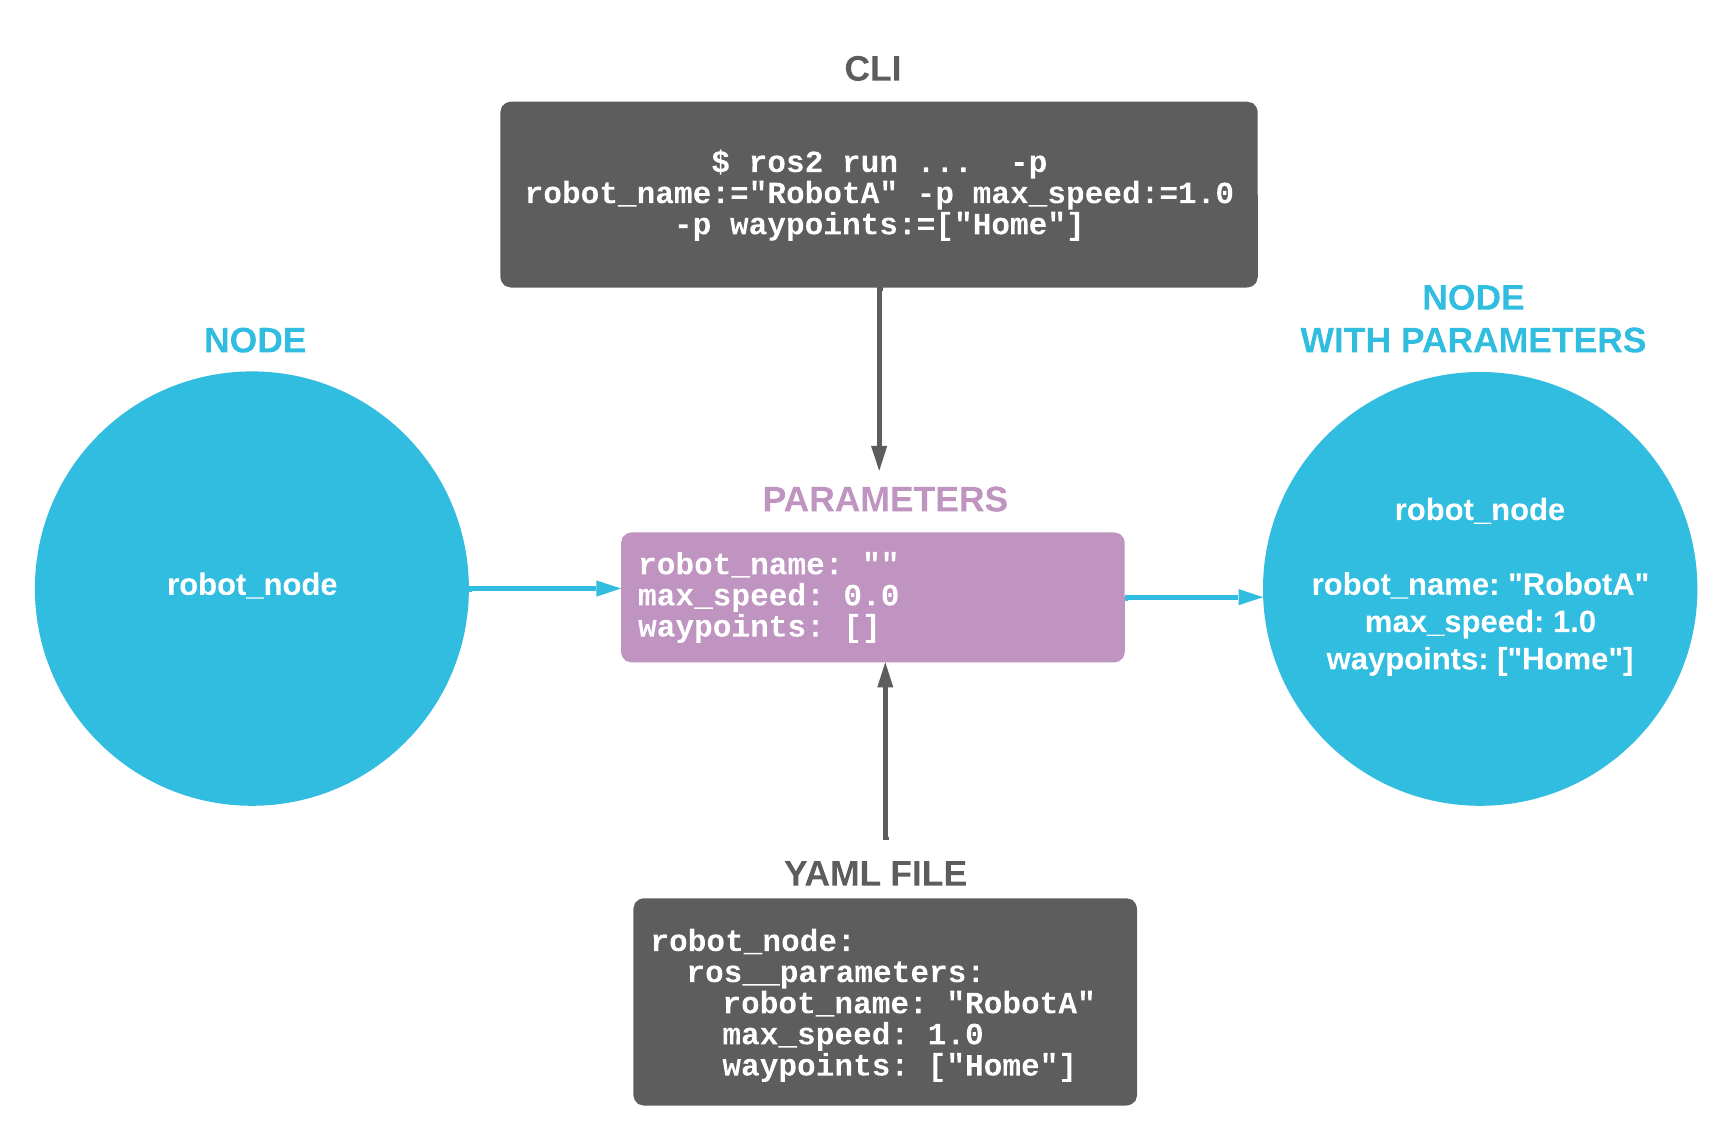
Hero image for How to Use ROS 2 Parameters

How to Use ROS 2 Parameters

LearnJul 25, 2024

Set up your ROS 2 nodes at startup to tailor their behavior to your specific needs.

Hero image for Autonomous Robot Navigation and Nav2

Autonomous Robot Navigation and Nav2

LearnJul 22, 2024

Navigation2, also known as Nav2: a framework for robotic ground navigation.

Hero image for Installing ROS 2 on macOS with Docker

Installing ROS 2 on macOS with Docker

LearnJul 19, 2024

Utilize Docker containers to quickly set up and begin ROS 2 development.

Hero image for Installing ROS 1 on macOS with Docker

Installing ROS 1 on macOS with Docker

LearnJul 18, 2024

Use Docker containers to get started with ROS 1 development.

Hero image for Using Rosbridge with ROS 2

Using Rosbridge with ROS 2

LearnJul 4, 2024

Talk to your ROS 2 robot from the web using WebSockets.

Hero image for A Practical Guide to Using ROS Diagnostics

A Practical Guide to Using ROS Diagnostics

LearnJun 17, 2024

Using ROS diagnostics in robotics operations to help scale your fleet.