Industries
Record ROS 2 data in more performant and configurable bag file format
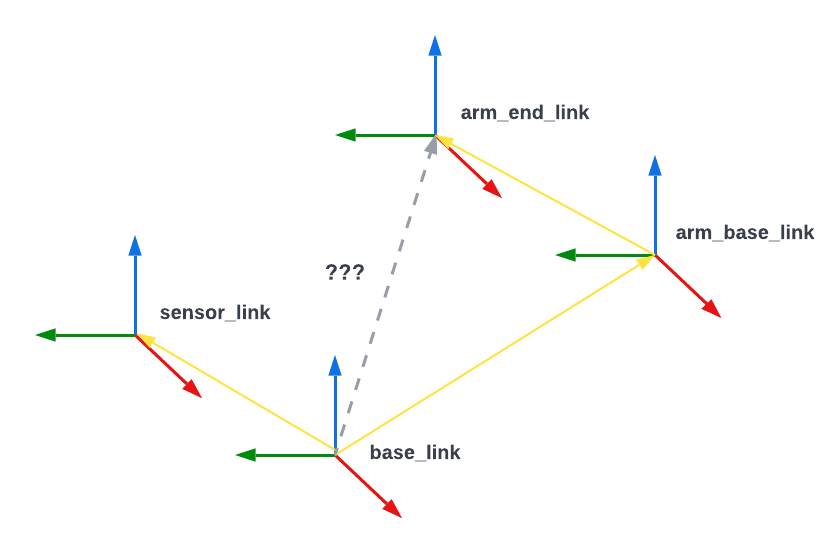
Defining how objects in a robot's world relate to each other
Analyze your FlatBuffers data with Foxglove
How we built a Spotlight Importer for MCAP files using Swift
Use message converters to visualize your custom messages
Use Foxglove's new color modes to customize your point clouds
Executing and configuring multiple ROS 1 nodes at once
Leveraging Foxglove to achieve podium places at Formula Student 2022
Annotate your robotics data with metadata-rich Events with Foxglove
Optimizing message loading and lookup for accurate data analysis
Announcing our newest security practices and data protection measures
Record and visualize your MCAP data with ROS 2 tooling
Accelerating the robotics revolution
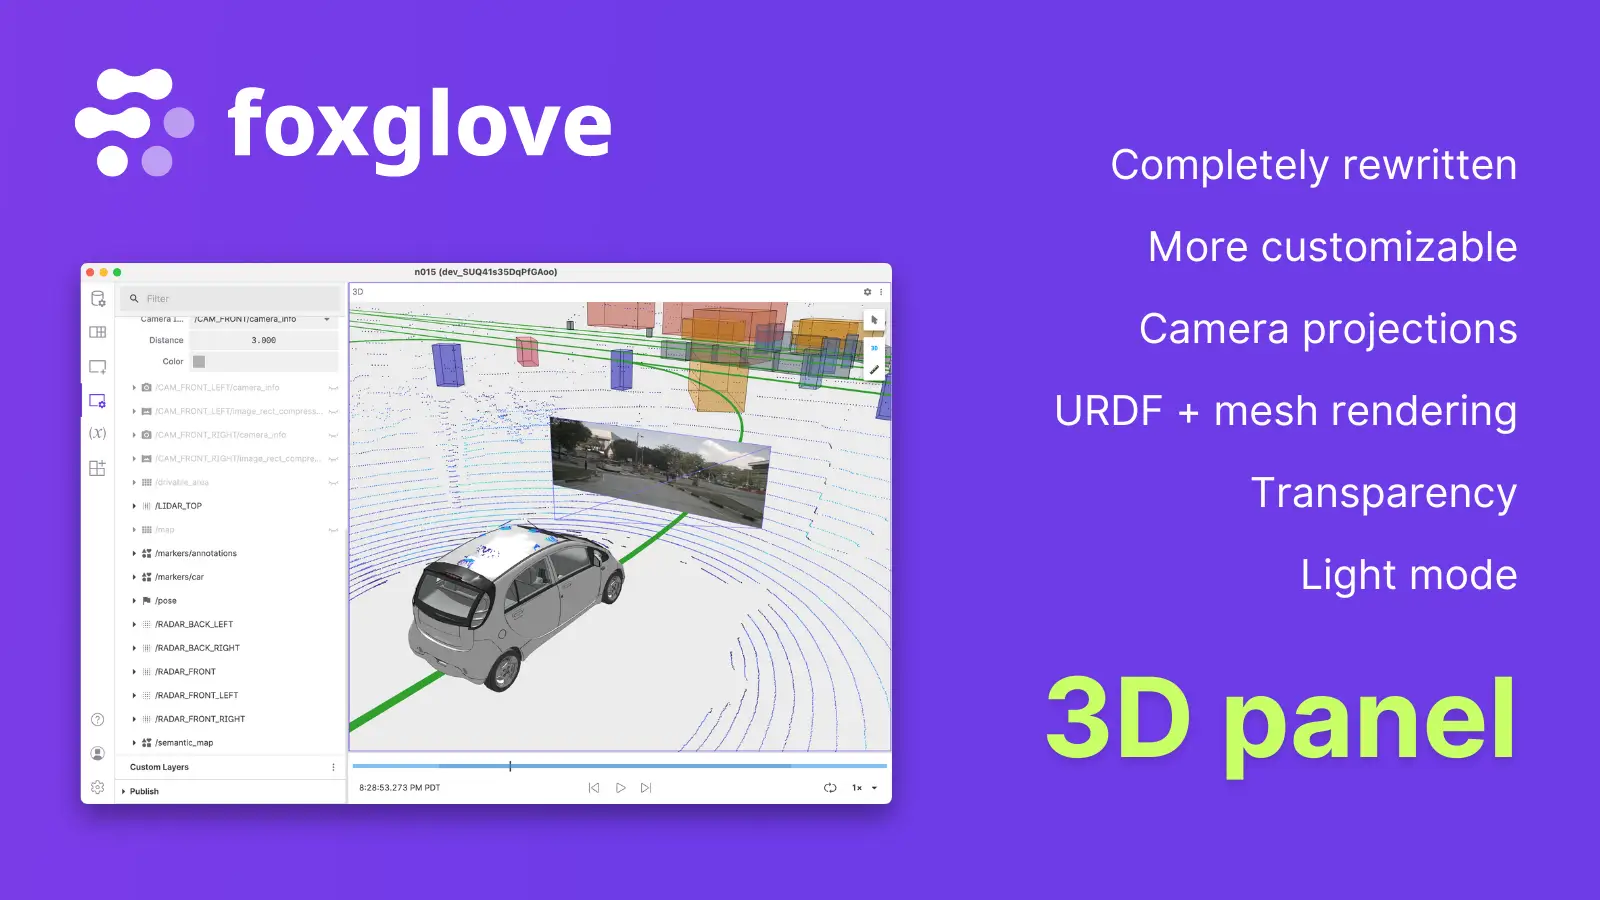
Visualize more types of 3D data with an easier-to-use interface
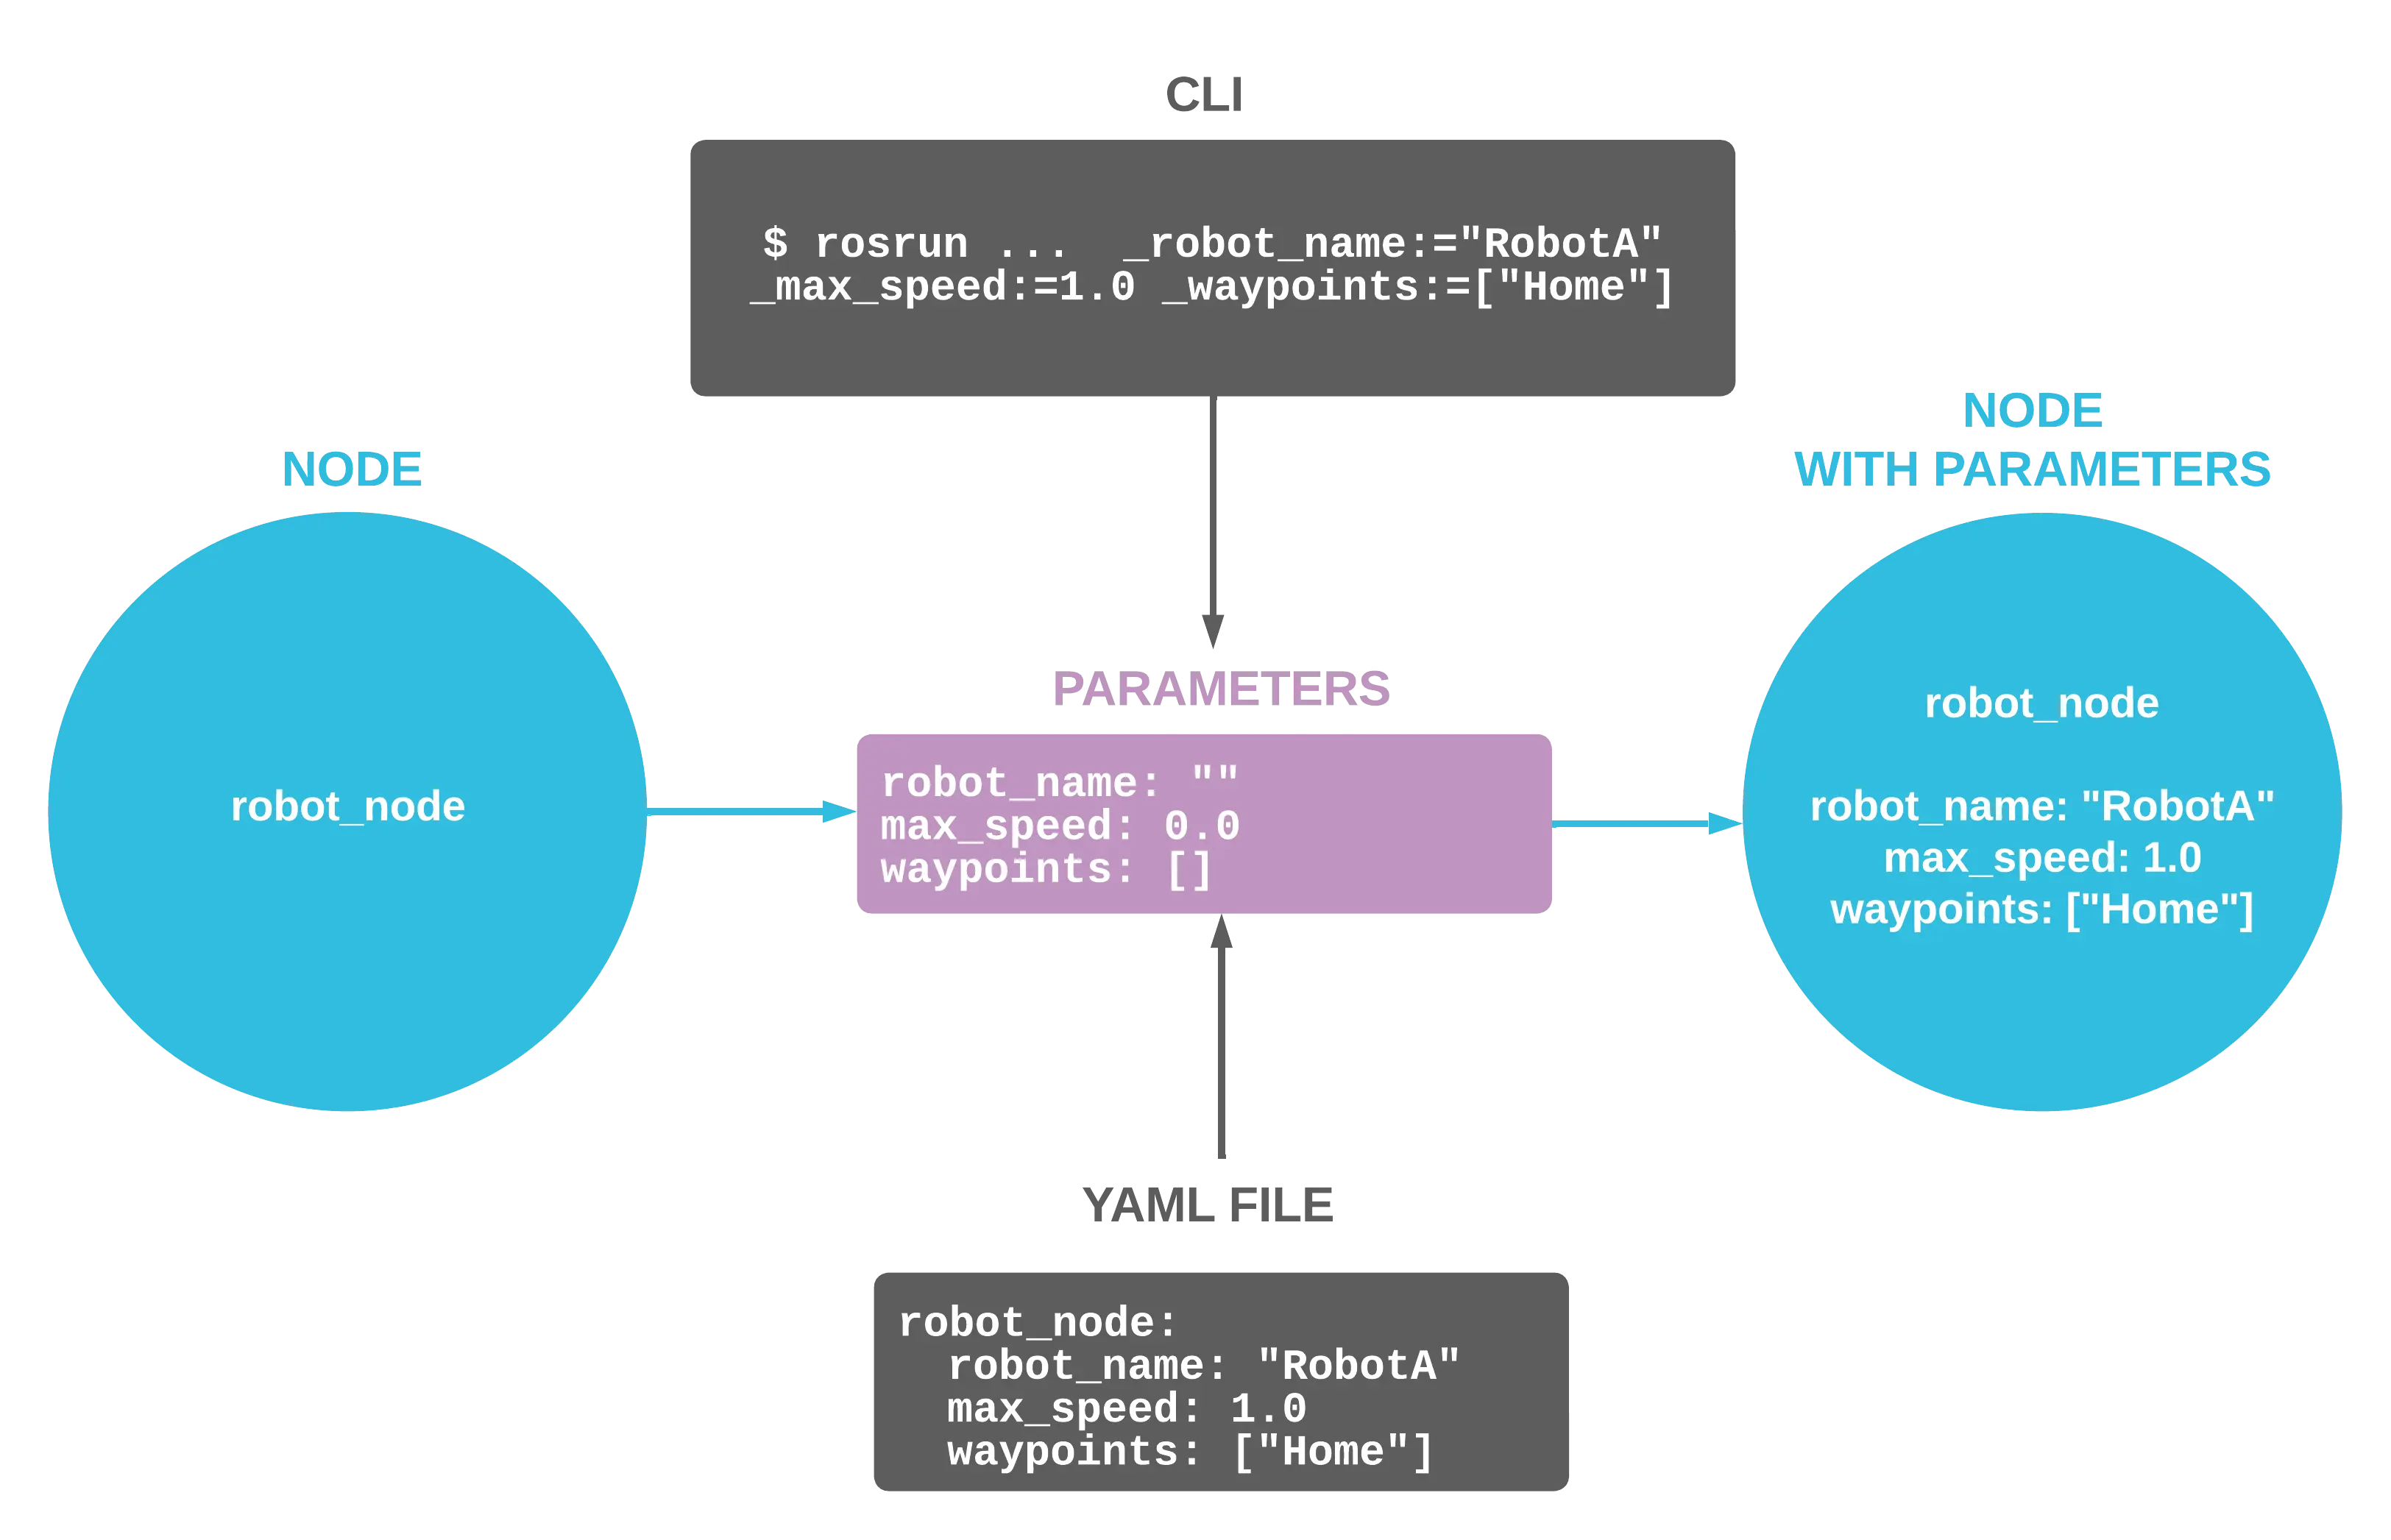
Configure your ROS nodes at startup to customize their behavior
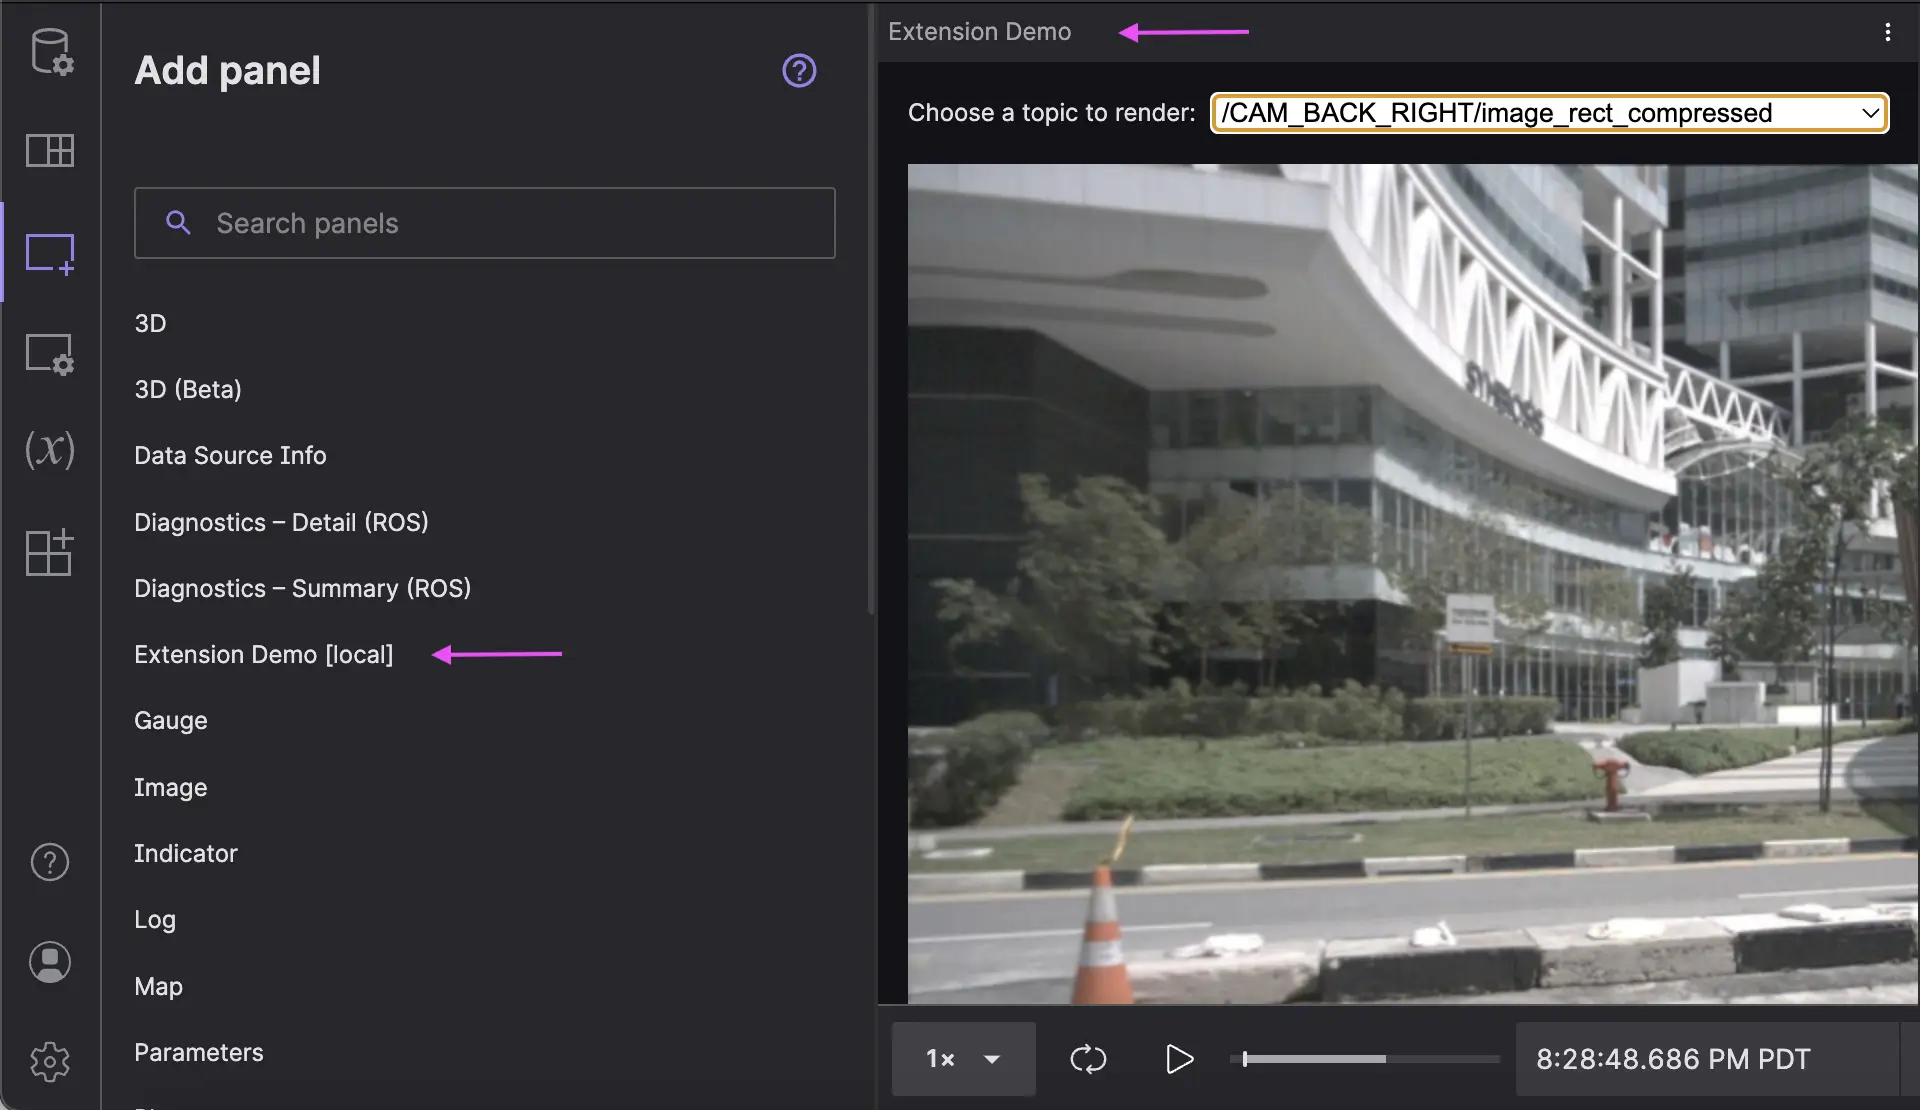
Create project-specific visualization tools for your robotics team
Store and explore your robotics data in self-contained MCAP files
Coordinate open-ended communication between your ROS 1 nodes
No posts found.