Industries
How Foxglove compares to RViz, the original visualization tool for ROS.
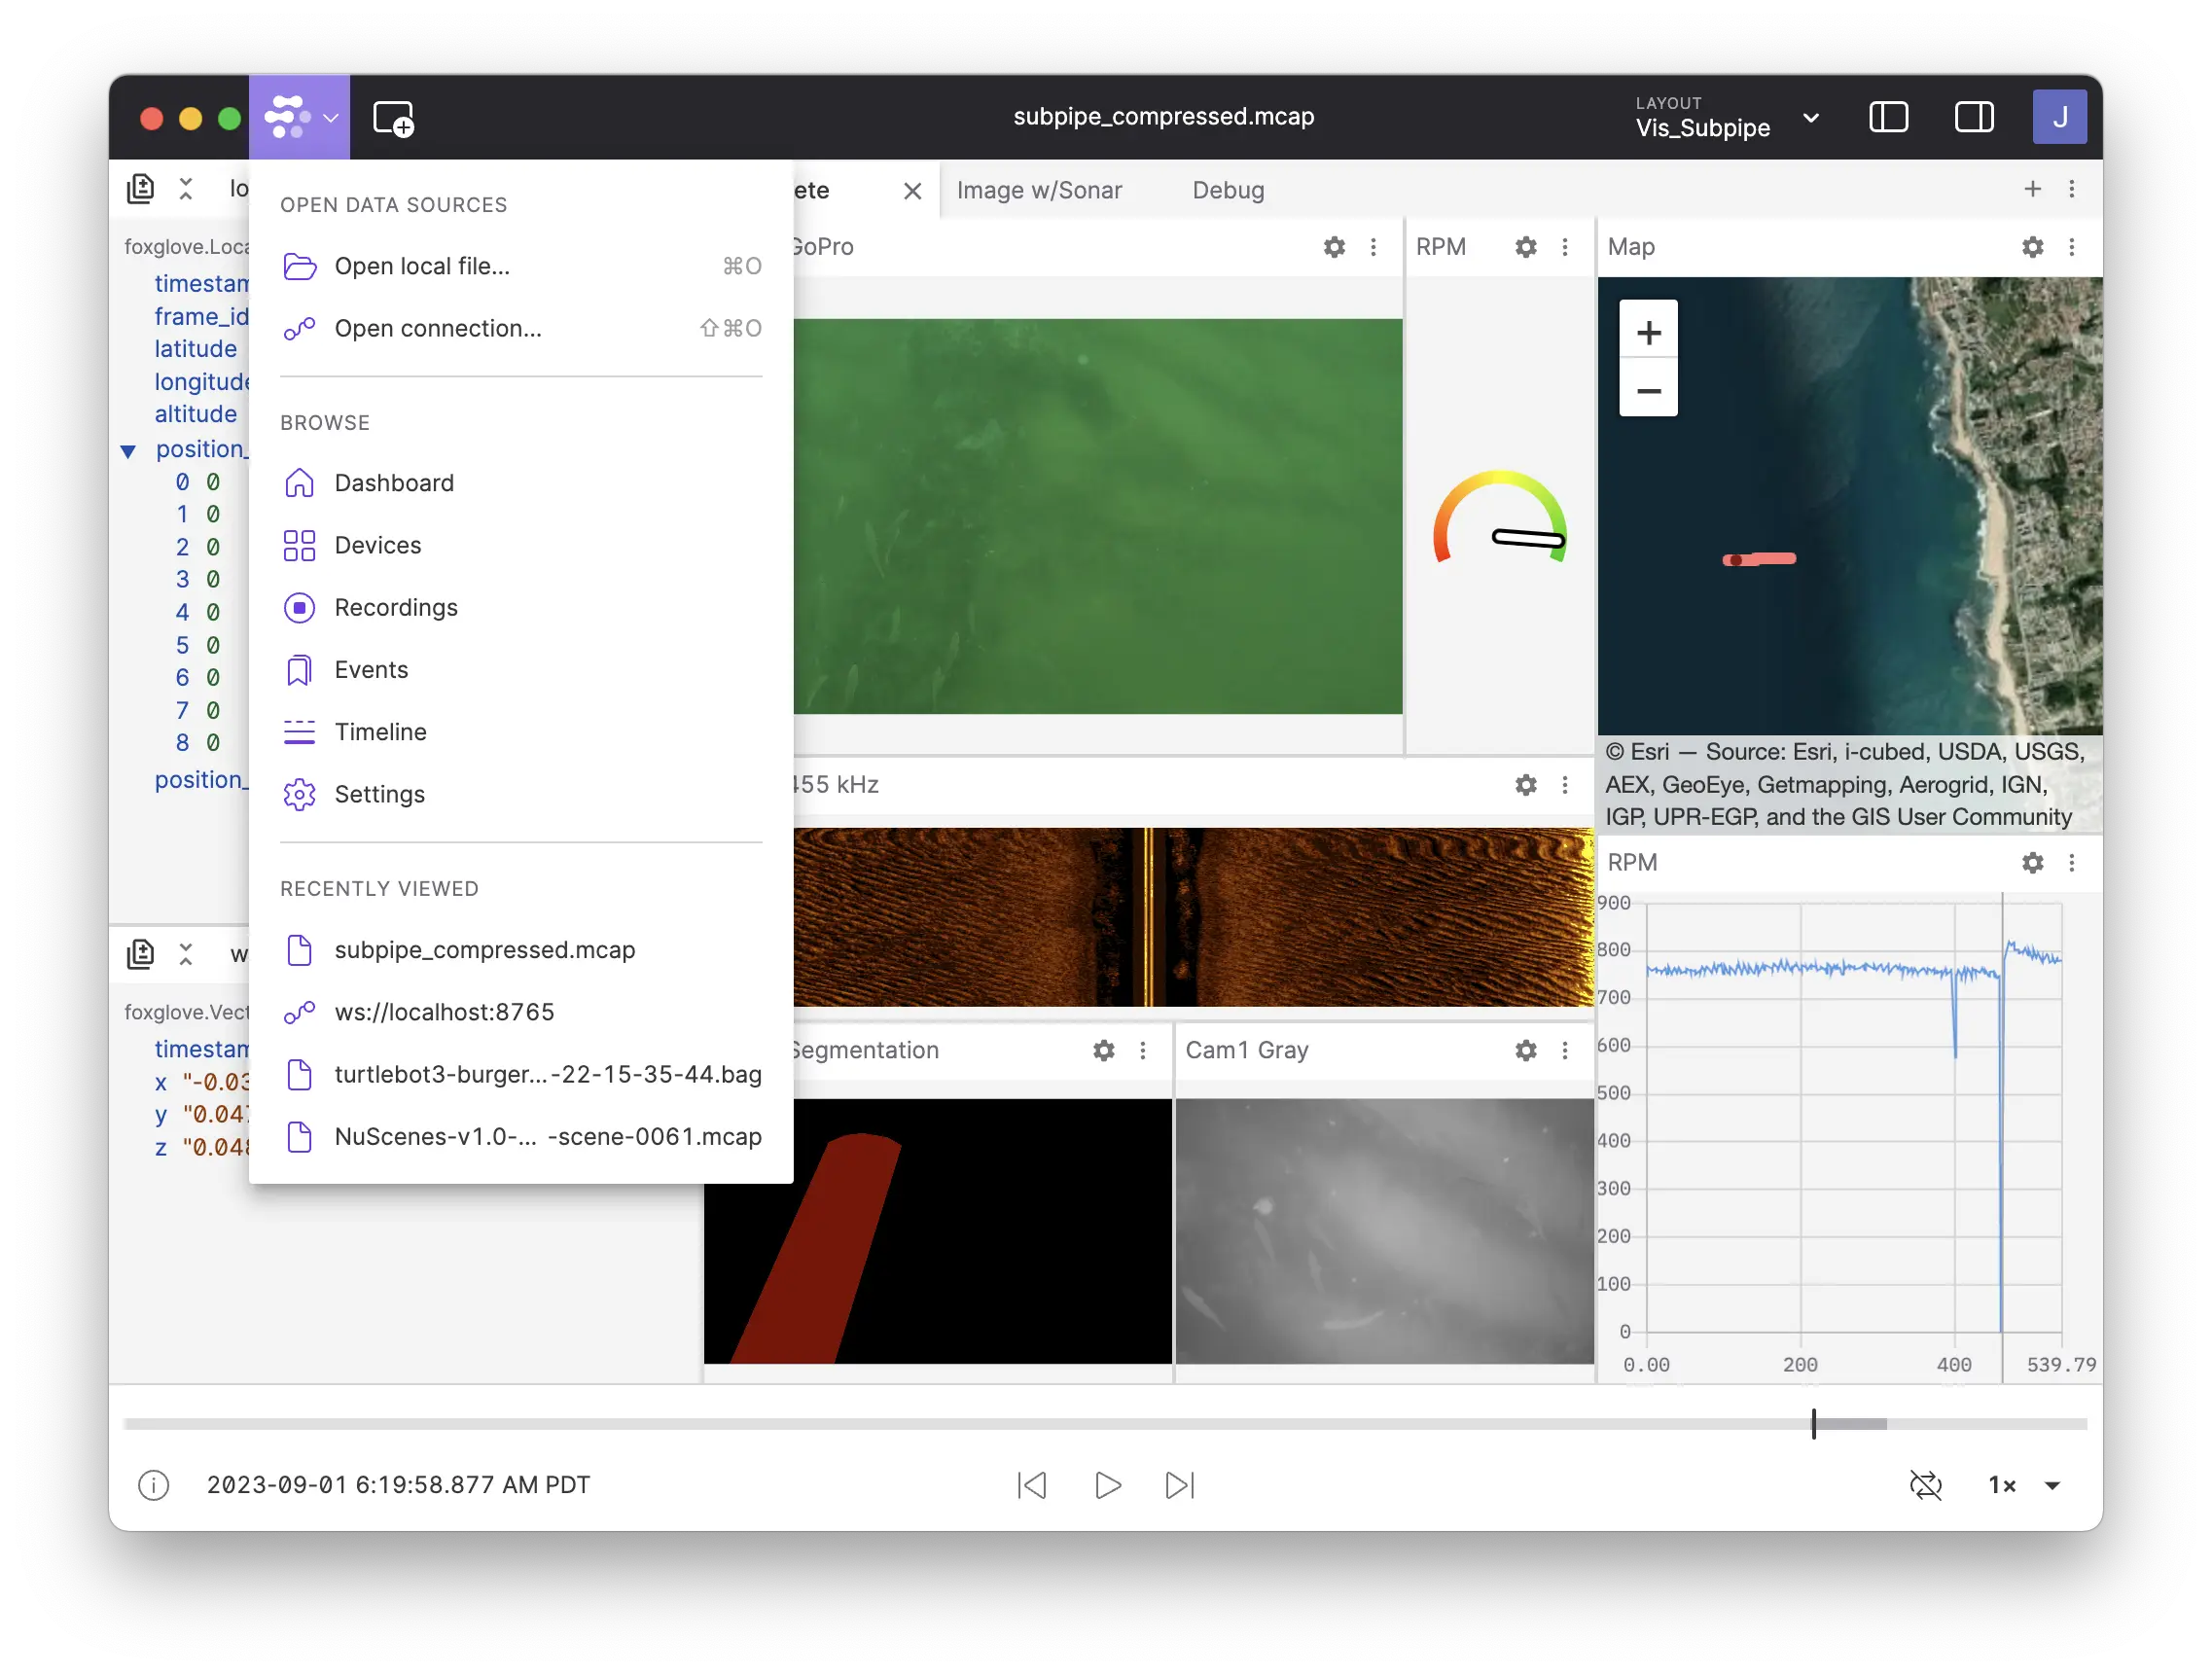
Play multiple .mcap files locally in Foxglove as if they were a single file.
A faster State Transitions panel that uses less memory.
How Foxglove compares to Webviz, Cruise’s original ROS data visualization tool.
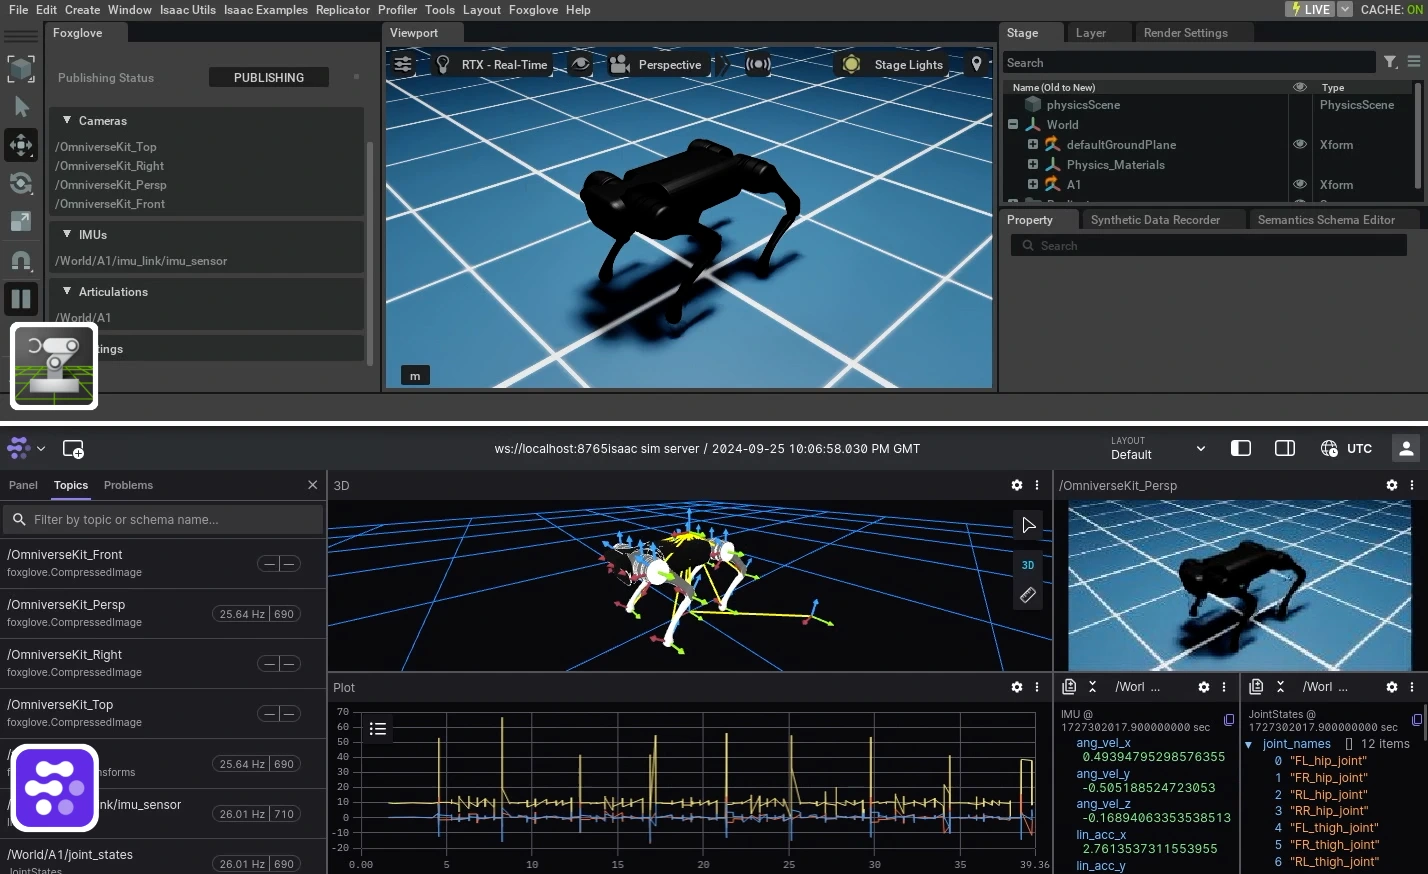
Visualizing NVIDIA Isaac Sim data using Foxglove’s custom extension.
New tools to help diagnose and resolve import errors.
React to changes in your data in real time
Setting a new standard for robotics observability
Run automations powered by your robotics data
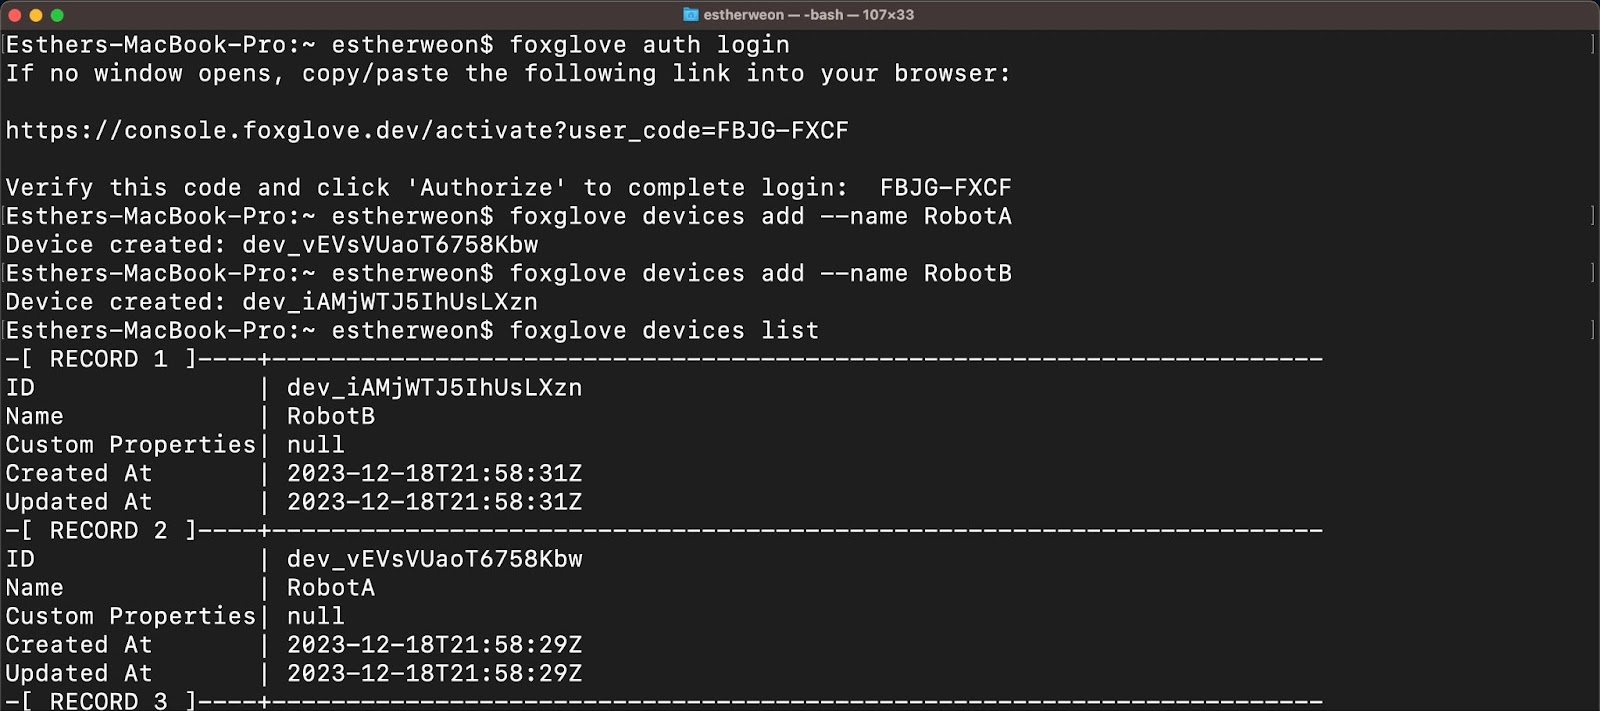
Simplify robotics development by managing data from the command line
Send data directly from your robots to Foxglove
Leverage powerful video codecs to substantially reduce your storage requirements
Allow your robotics team to securely sign in to Foxglove with a single click
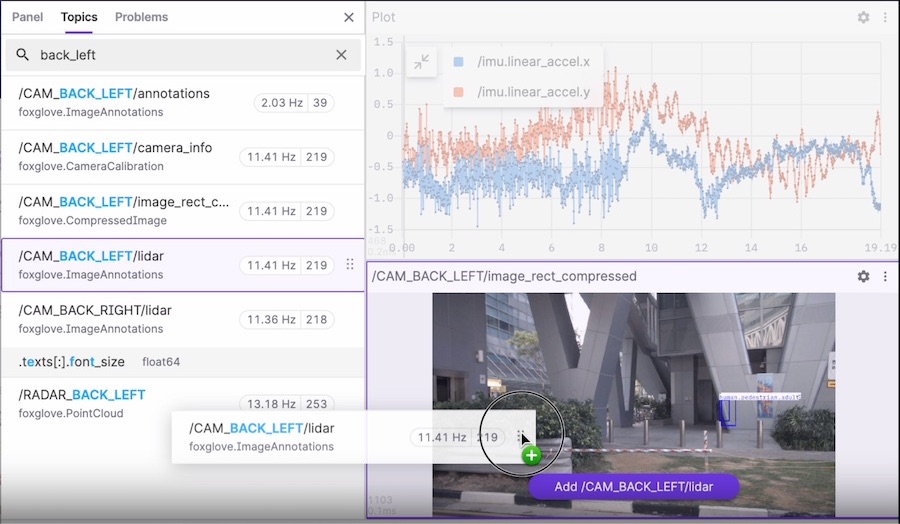
Drag-and-drop topics into select panels for instant visualization
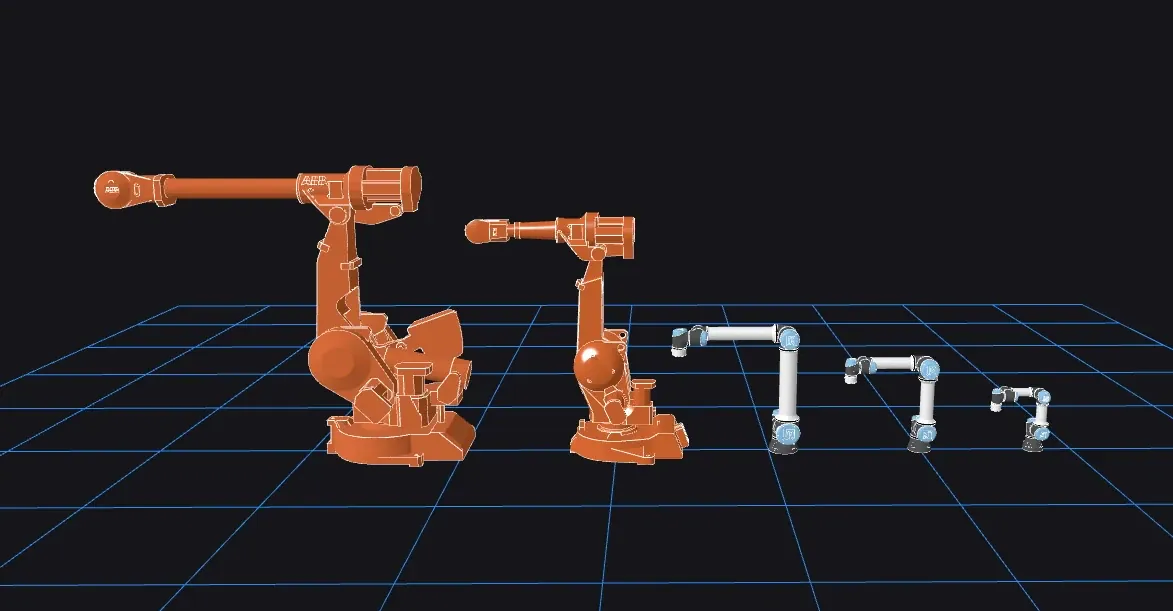
Fetch remote meshes, use additional URDF sources, and visualize collision geometries
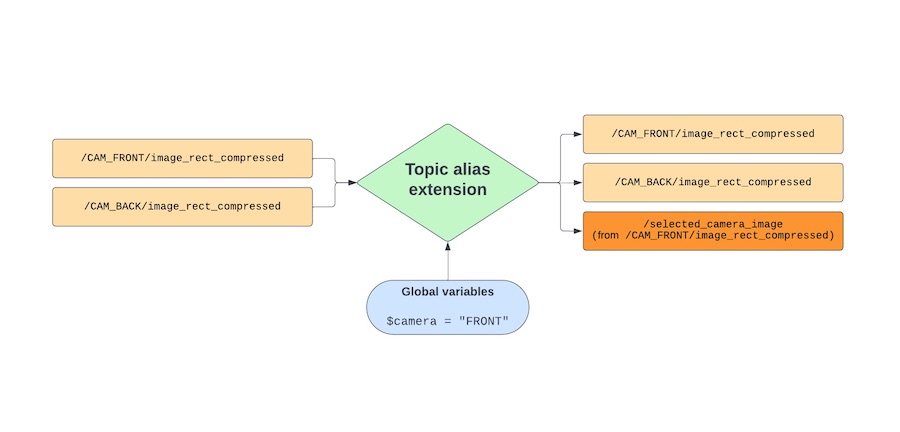
Dynamically rename topics to better organize and navigate complex datasets
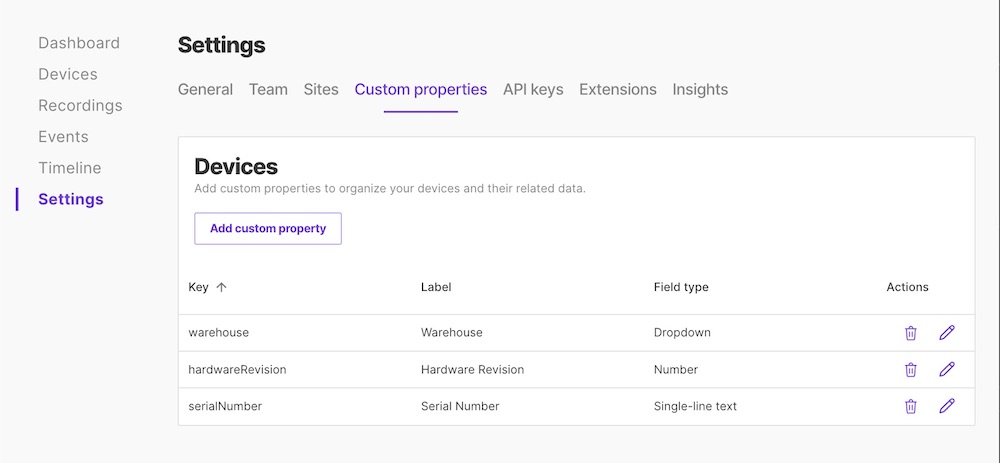
Add metadata to your team’s devices for discoverability and search
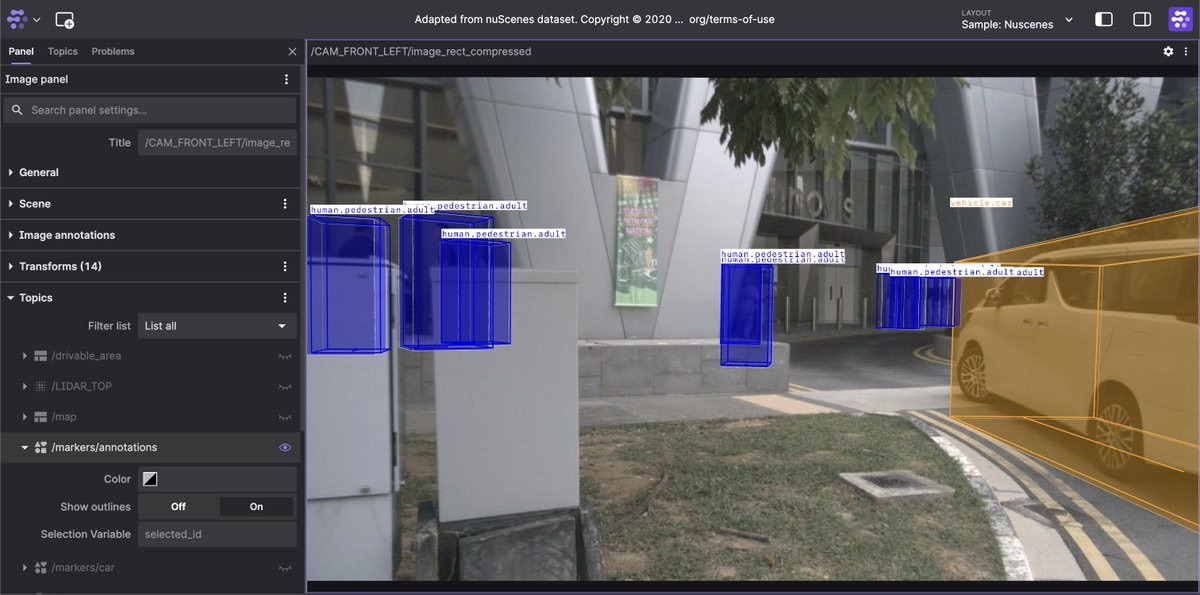
Use 2D annotations and 3D markers to add context to your camera images
No posts found.